Workshop Logo

IEEE/RSJ IROS WS — Geometric Representations in Robotics
Structured priors, metrics, constraints & groundings for Manipulation

Accepted Papers

Sponsored by:
IEEE RAS TC on Algorithms for Planning and Control of Robot Motion

Below is the list of accepted contributions for the 2nd Workshop on Geometric-Aware Representations for Manipulation at IROS 2026. Click on any teaser figure to enlarge it, or click Download Paper (PDF) to view the full camera-ready paper.

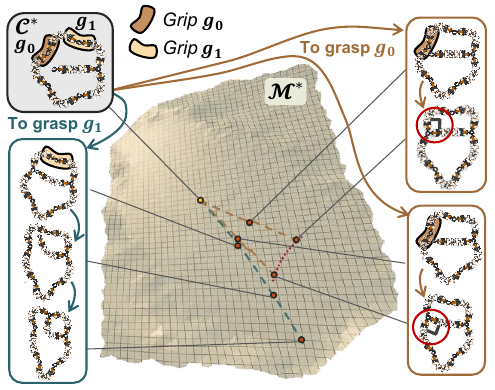
Paper #01 — Geometric–Topological Representations for Self-Reconfiguration Planning of Continuum Modular Robots

Authors: Zhefeng Huang, Yilin Cai, Yifan Wang, Yue Chen

Institutions: Georgia Institute of Technology; Emory University

Download Paper (PDF)
Paper #01 Teaser Figure

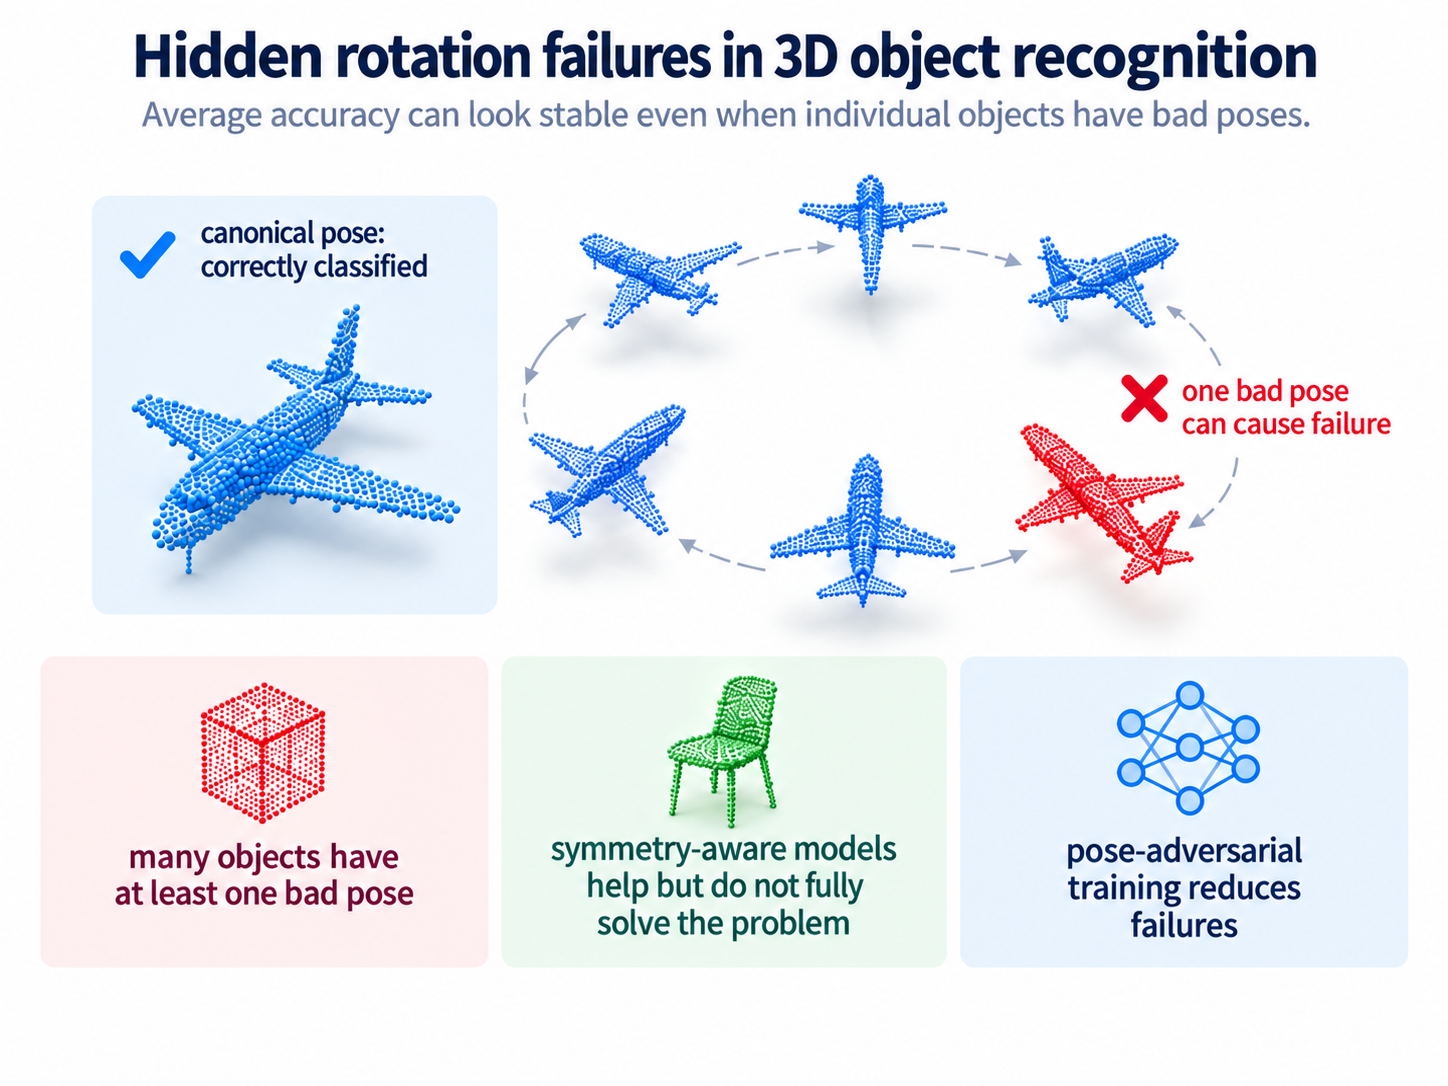
Paper #02 — Aggregate Pose Accuracy Is Not Invariance: Worst-Case-Over-Orbit Auditing for Robot Perception

Author: Ali Baheri

Institution: Rochester Institute of Technology

Download Paper (PDF)
Paper #02 Teaser Figure

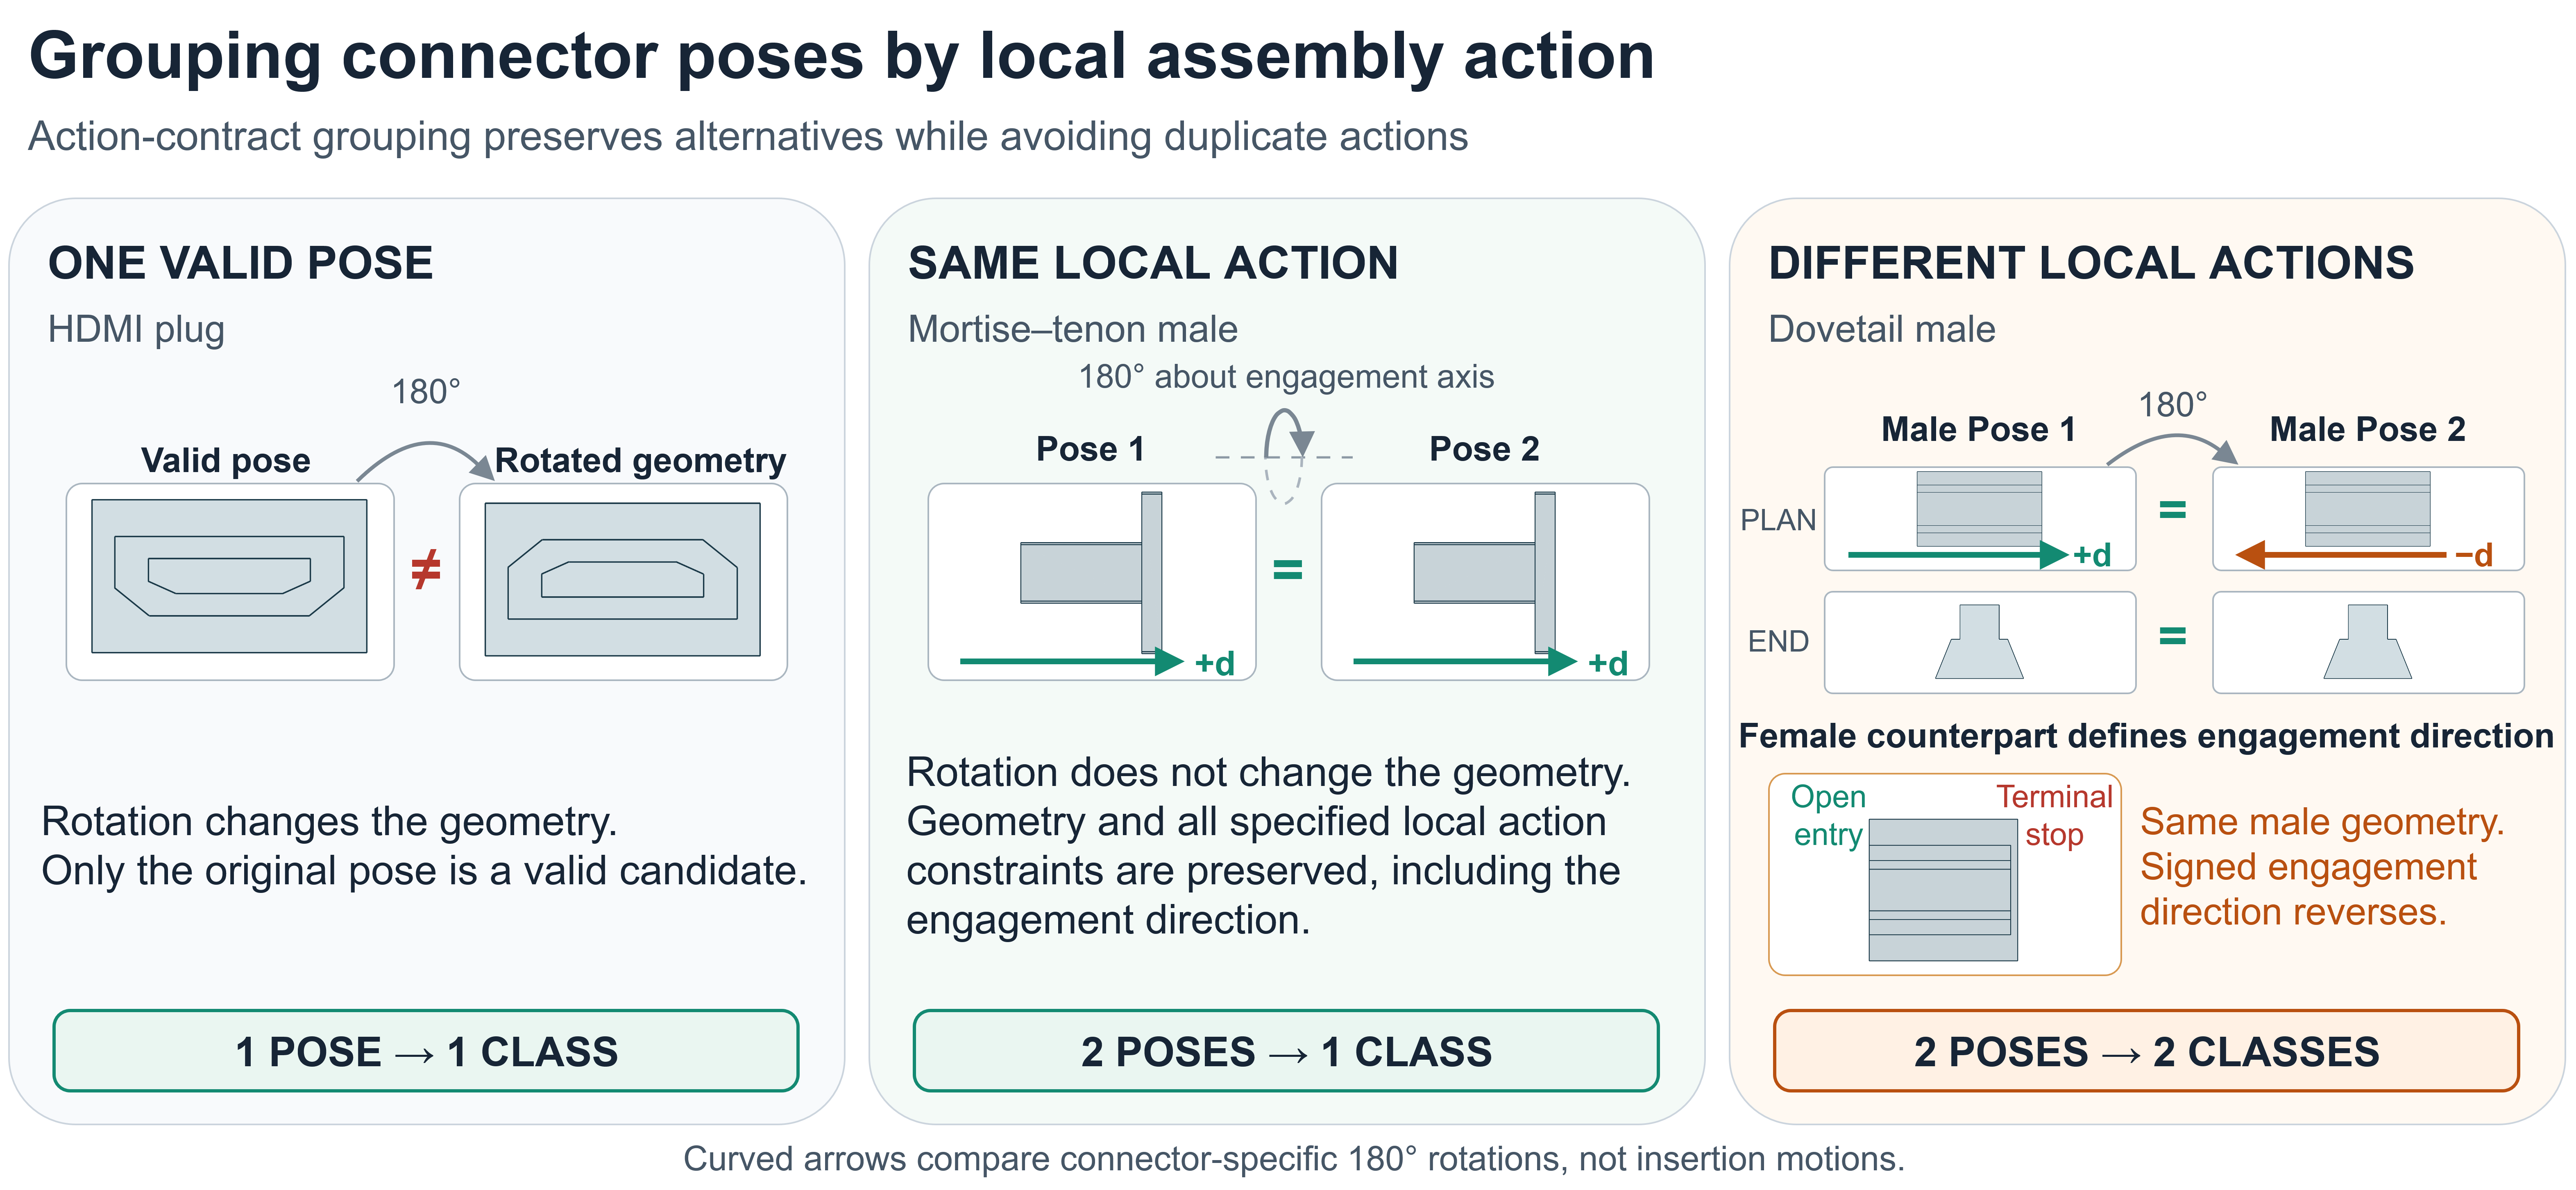
Paper #03 — Action-Contract Grouping for B-rep Connector Poses: Separating Geometric Symmetry from Local Assembly Action Equivalence

Authors: Nathan Espley-Plumb, Windo Hutabarat, Jonathan Aitken, Ashutosh Tiwari

Institution: The University of Sheffield

Download Paper (PDF)
Paper #03 Teaser Figure

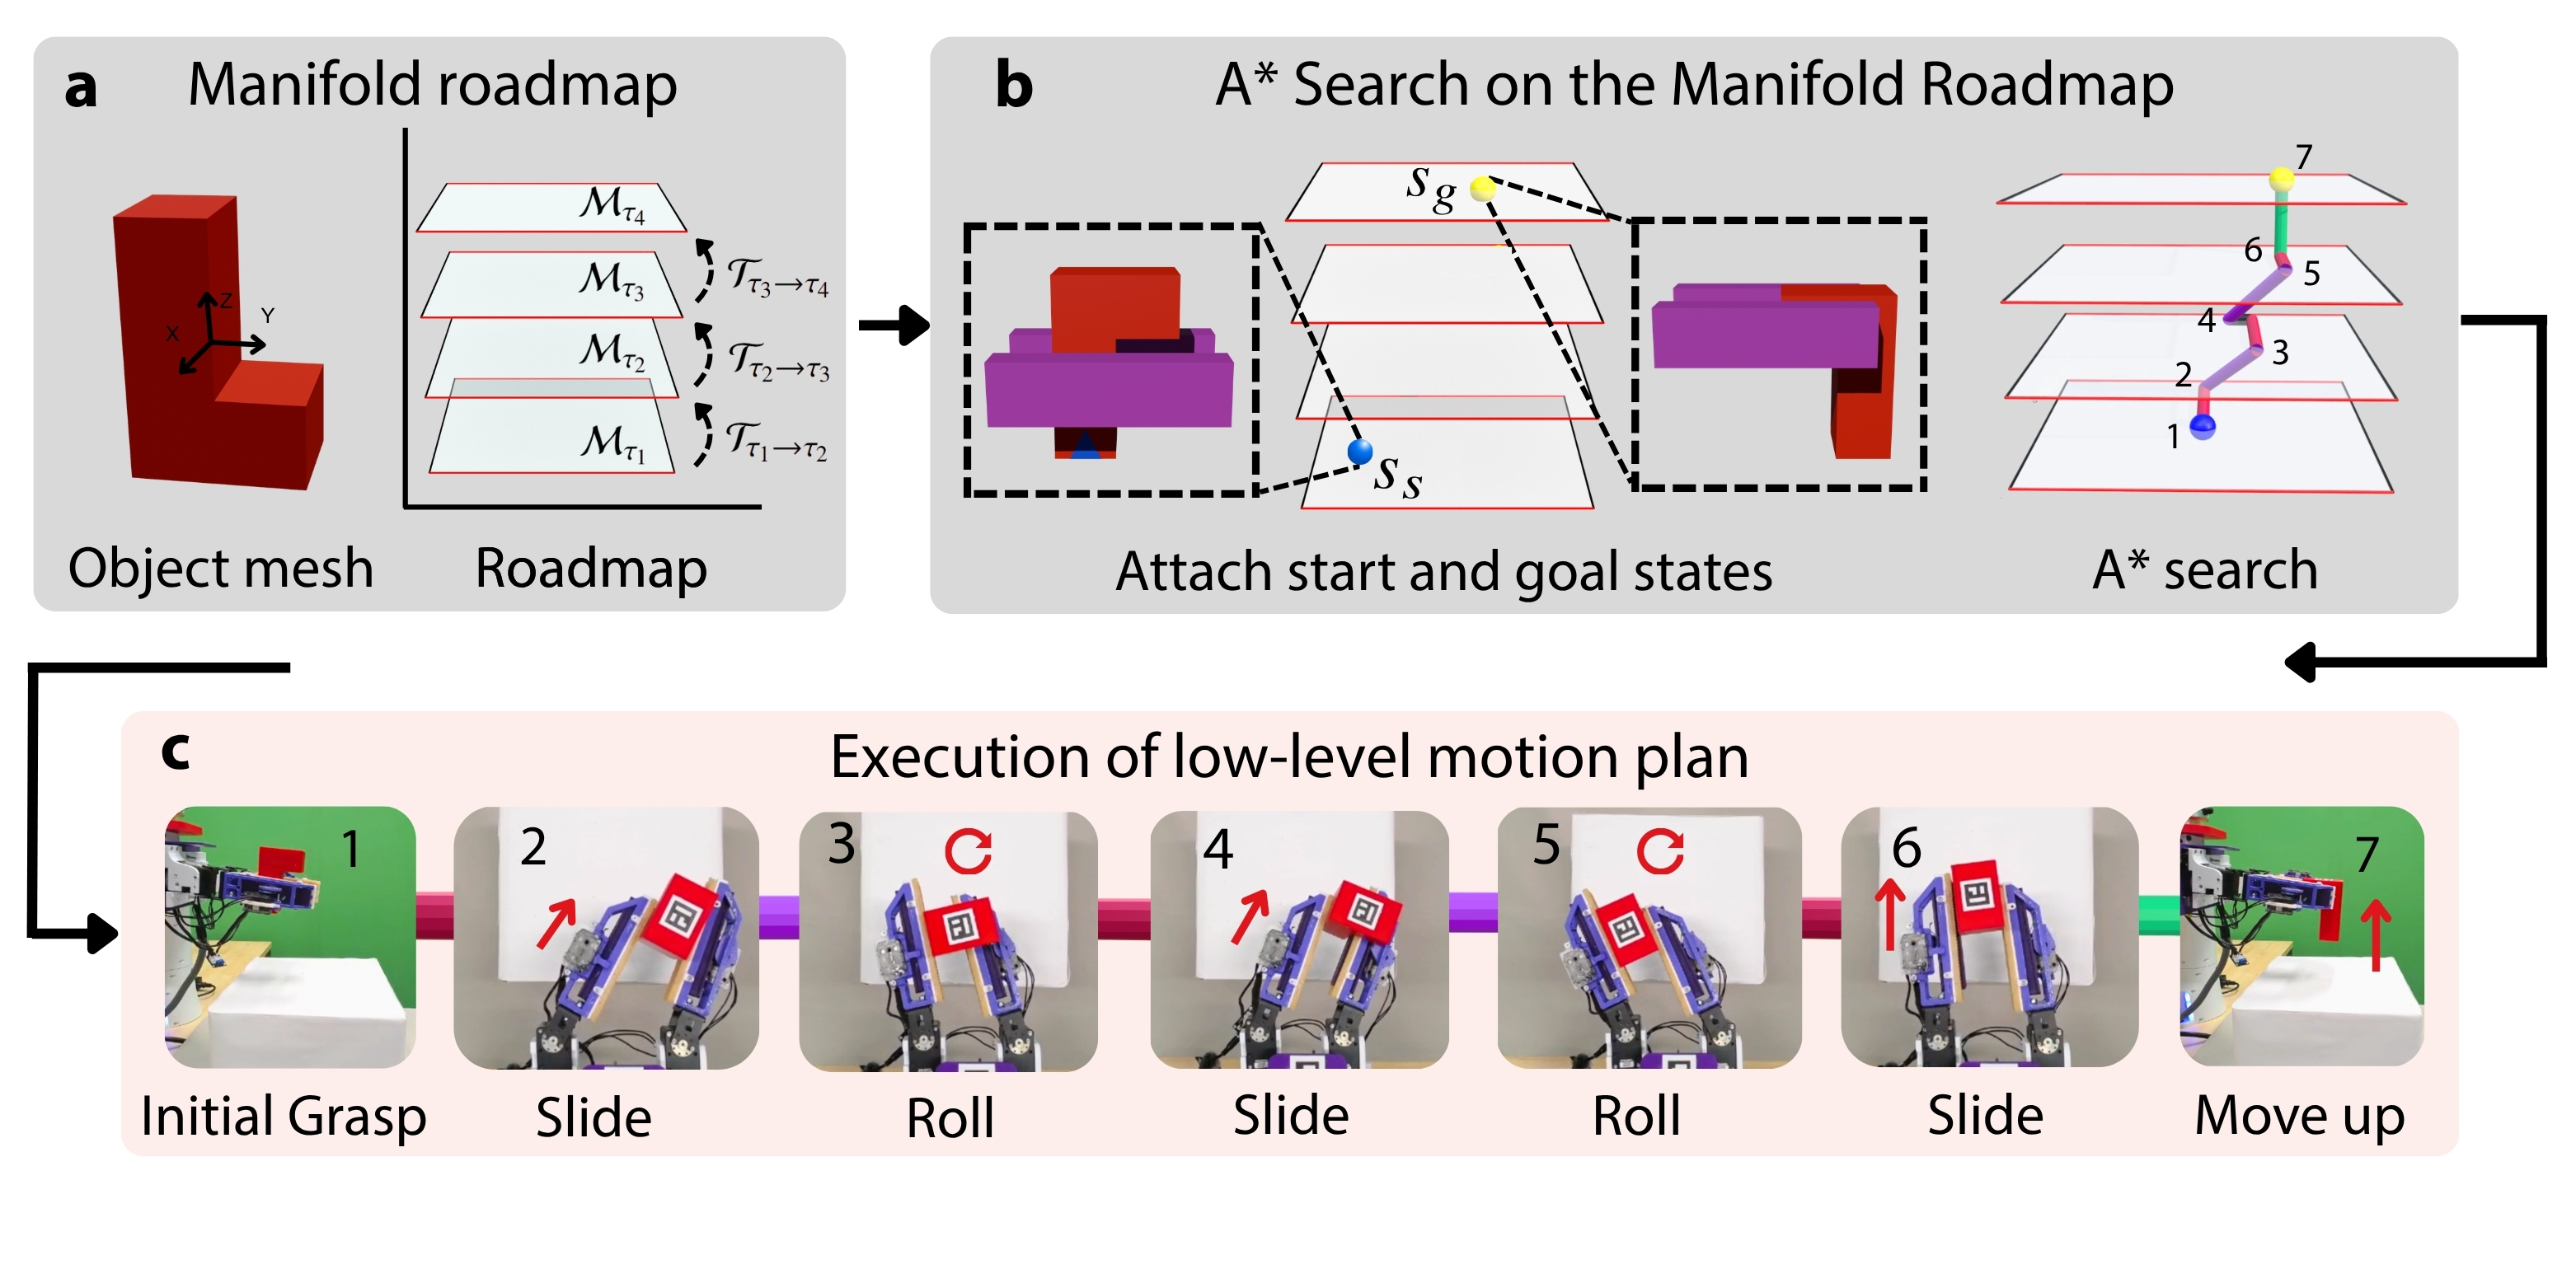
Paper #04 — Contact-Topology Manifolds in a Combined Finger–Object State Space: A Geometric Representation for Active-Surface In-Hand Manipulation

Authors: Shambhuraj A. Mane, Andrew S. Morgan, Berk Calli

Institutions: Worcester Polytechnic Institute; RAI Institute

Download Paper (PDF)
Paper #04 Teaser Figure

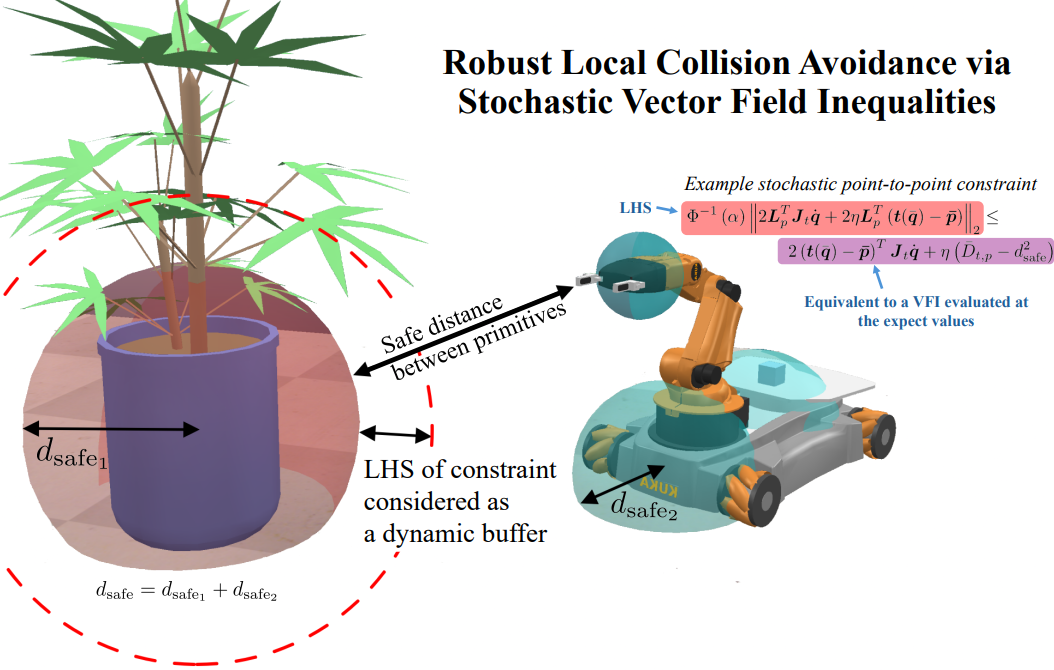
Paper #05 — Robust Local Collision Avoidance via Stochastic Vector Field Inequalities

Authors: Joshua R. Bettles, Yang Song, Bruno Vilhena Adorno, Joaquin Carrasco

Institution: The University of Manchester

Download Paper (PDF)
Paper #05 Teaser Figure

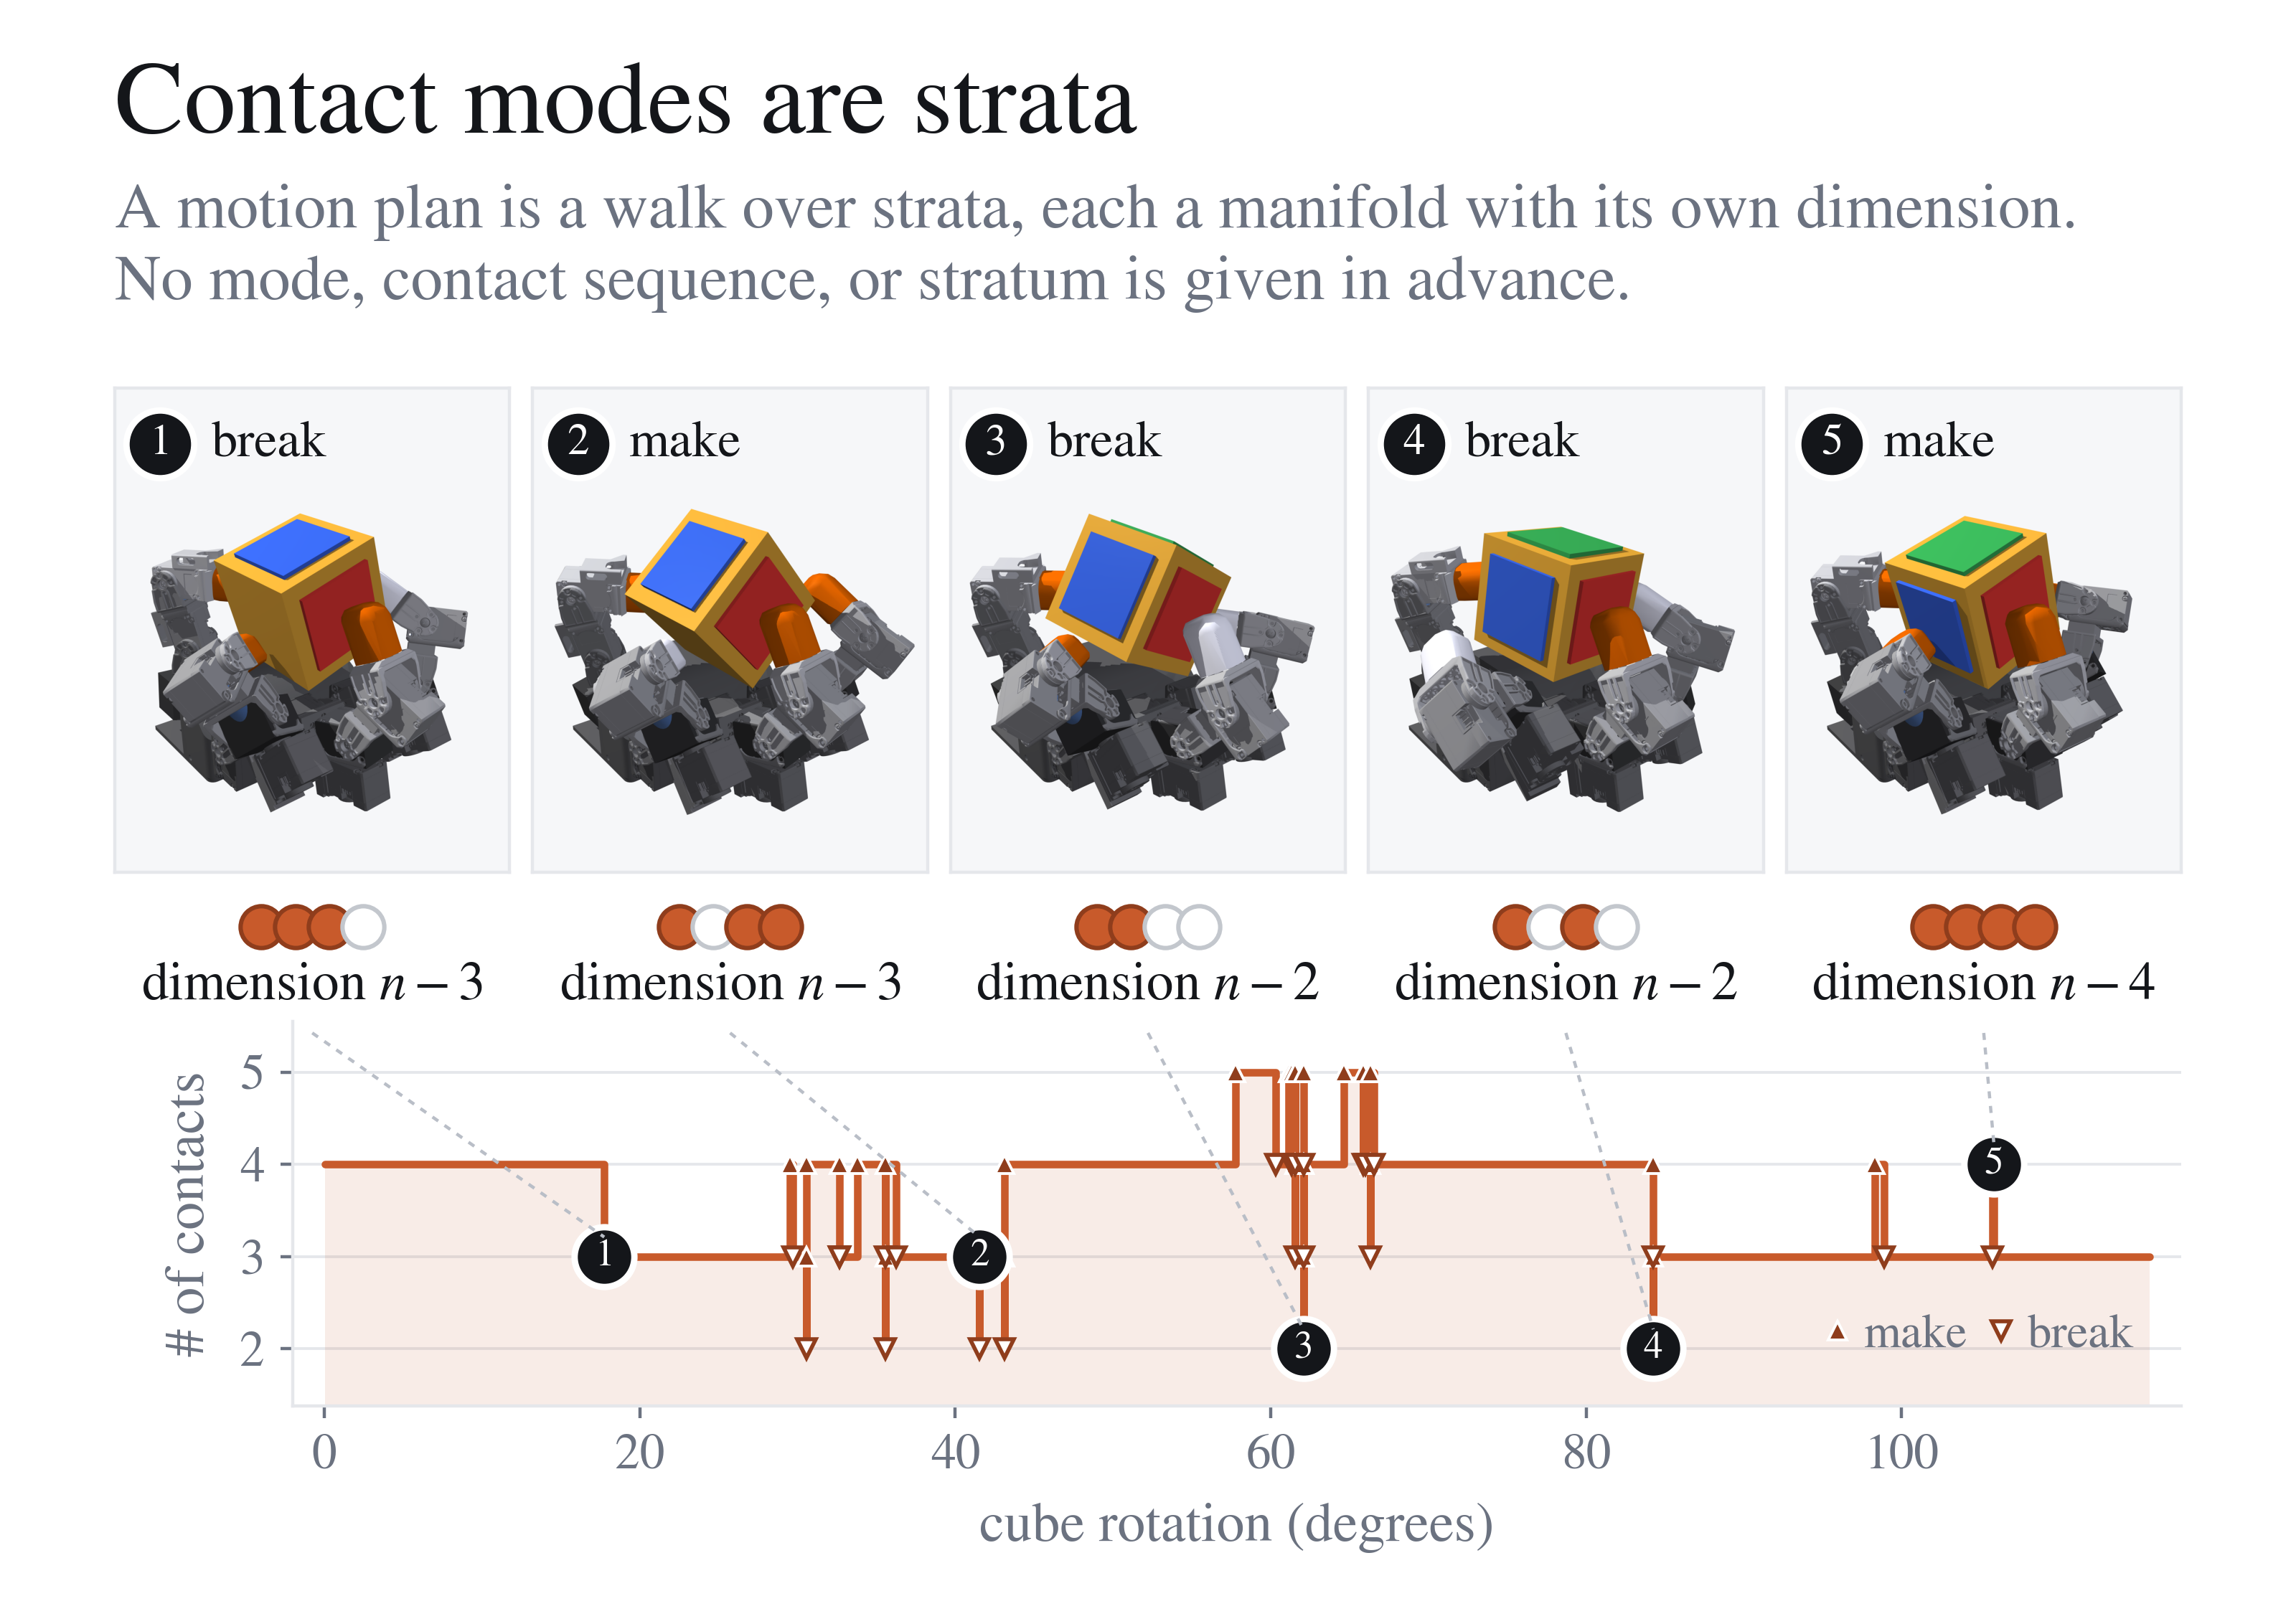
Paper #06 — Contact Modes Are Strata: What Geometric Structure Buys in Discrete–Continuous Planning

Authors: Phone Thiha Kyaw, Jonathan Kelly

Institution: University of Toronto Institute for Aerospace Studies (UTIAS)

Download Paper (PDF)
Paper #06 Teaser Figure

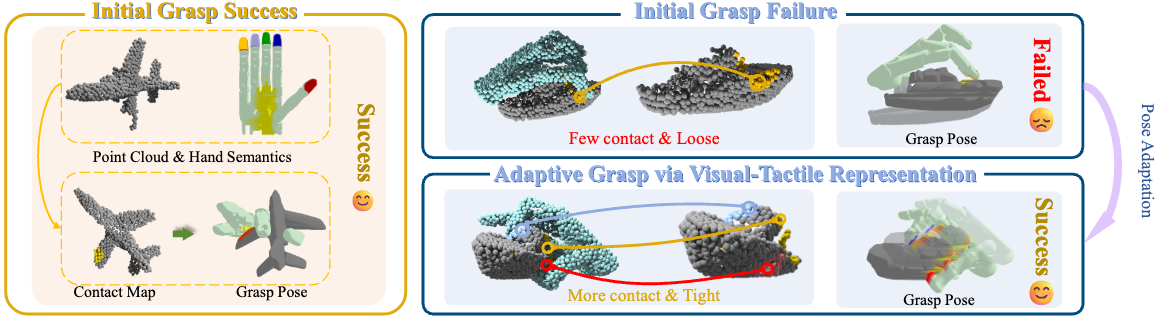
Paper #07 — AdaDexGrasp: Adaptive Dexterous Grasping via 3D Visuo-Tactile Representation Fusion

Authors: Xirui Liang, Jingkai Xu, Jiaqi Liang, Yuran Wang, Ruochong Li, Yuanpei Chen, Masayoshi Tomizuka, Wei Zhan, Ruihai Wu

Institutions: University of California, Berkeley; Peking University; The Hong Kong University of Science and Technology

Download Paper (PDF)
Paper #07 Teaser Figure

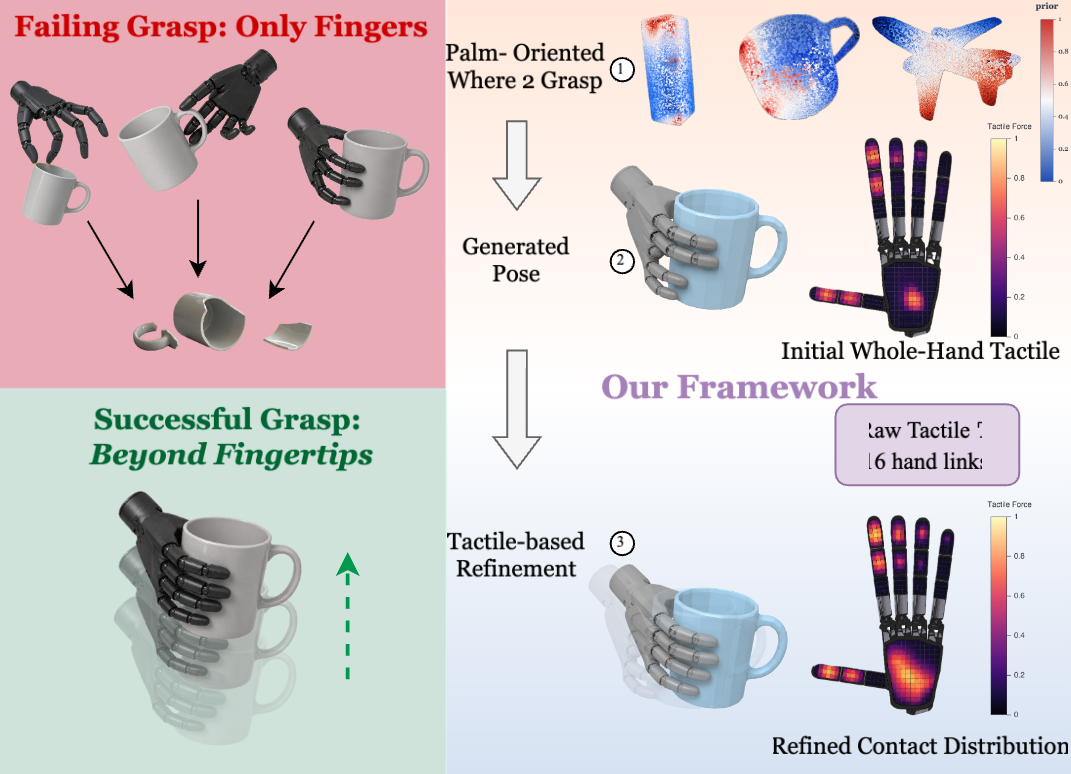
Paper #08 — Beyond Fingertips: From Palm Priors to Tactile Refinement for Generalizable Dexterous Grasping

Authors: Zhen Yuan, Ruoxiang Huang, Junchun Yu, Yuran Wang, Guanqi He, Masayoshi Tomizuka, Wei Zhan, Ruihai Wu

Institutions: University of California, Berkeley; University of Hong Kong; Peking University; City University of Hong Kong; Carnegie Mellon University

Download Paper (PDF)
Paper #08 Teaser Figure

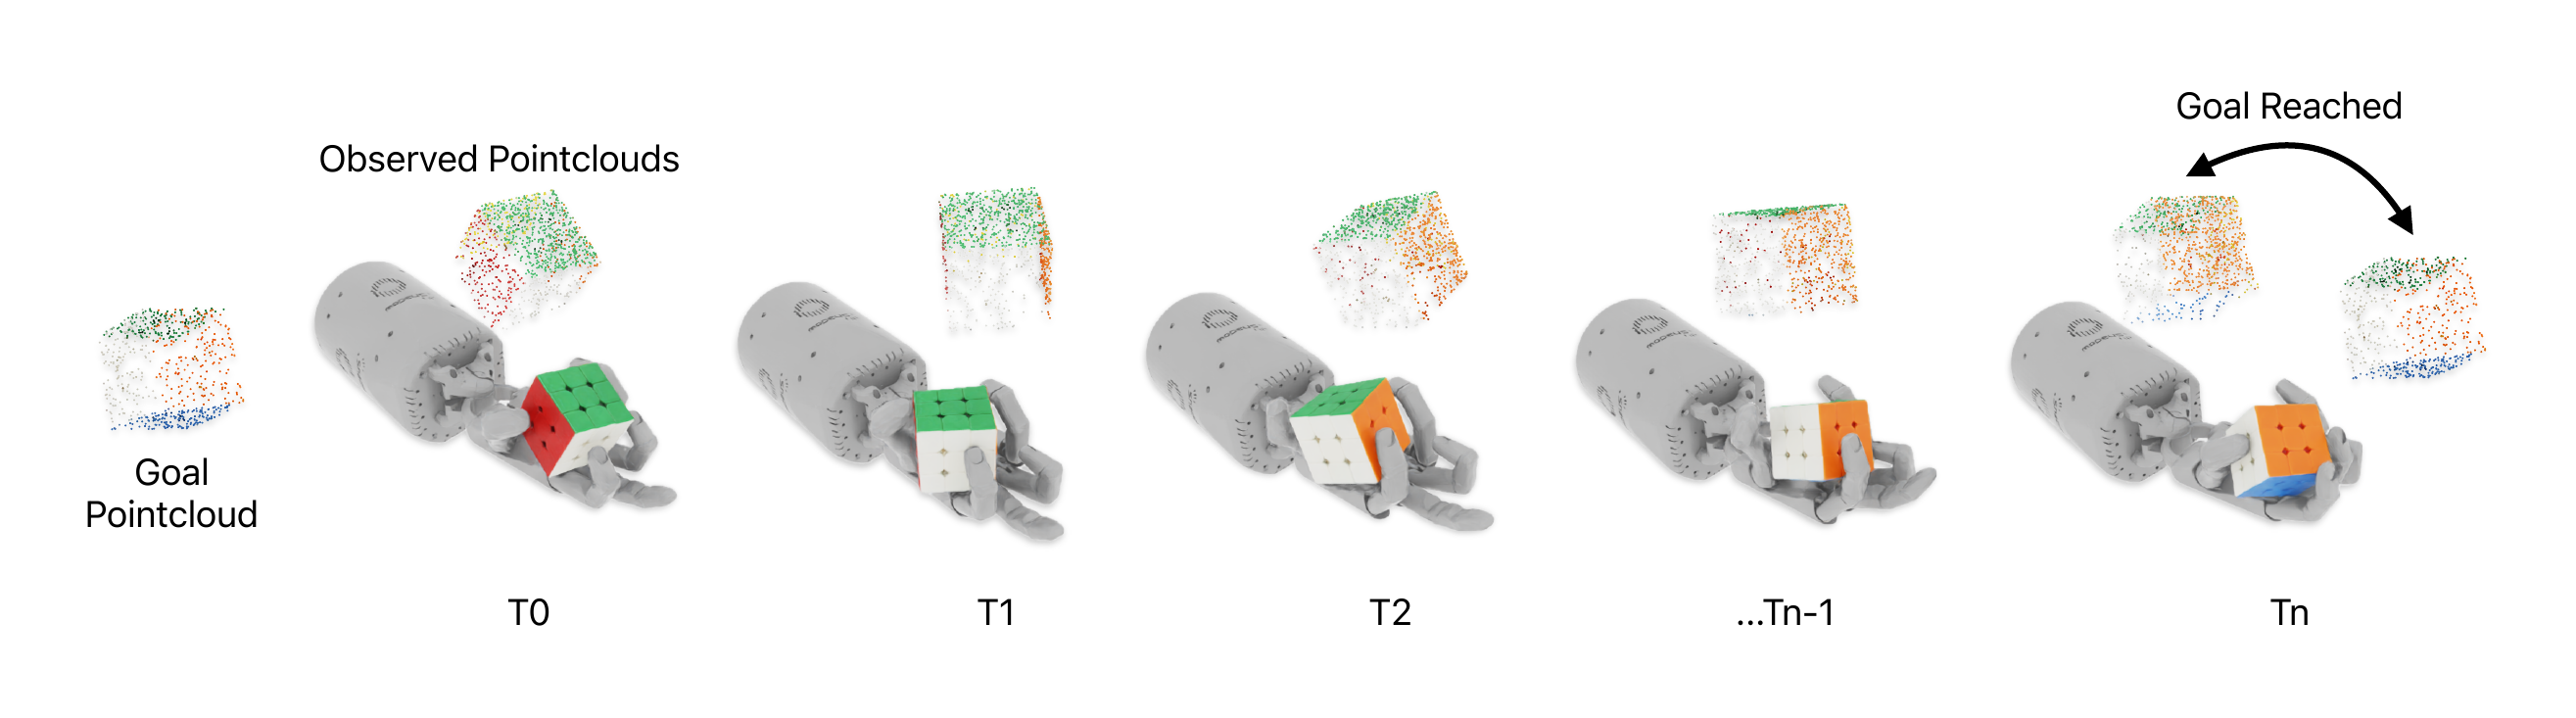
Paper #09 — Rotation-Aware Point-Cloud Embeddings for Vision-Based In-Hand Reorientation

Authors: Yashom Dighe, Karthik Dantu

Institution: University at Buffalo

Download Paper (PDF)
Paper #09 Teaser Figure

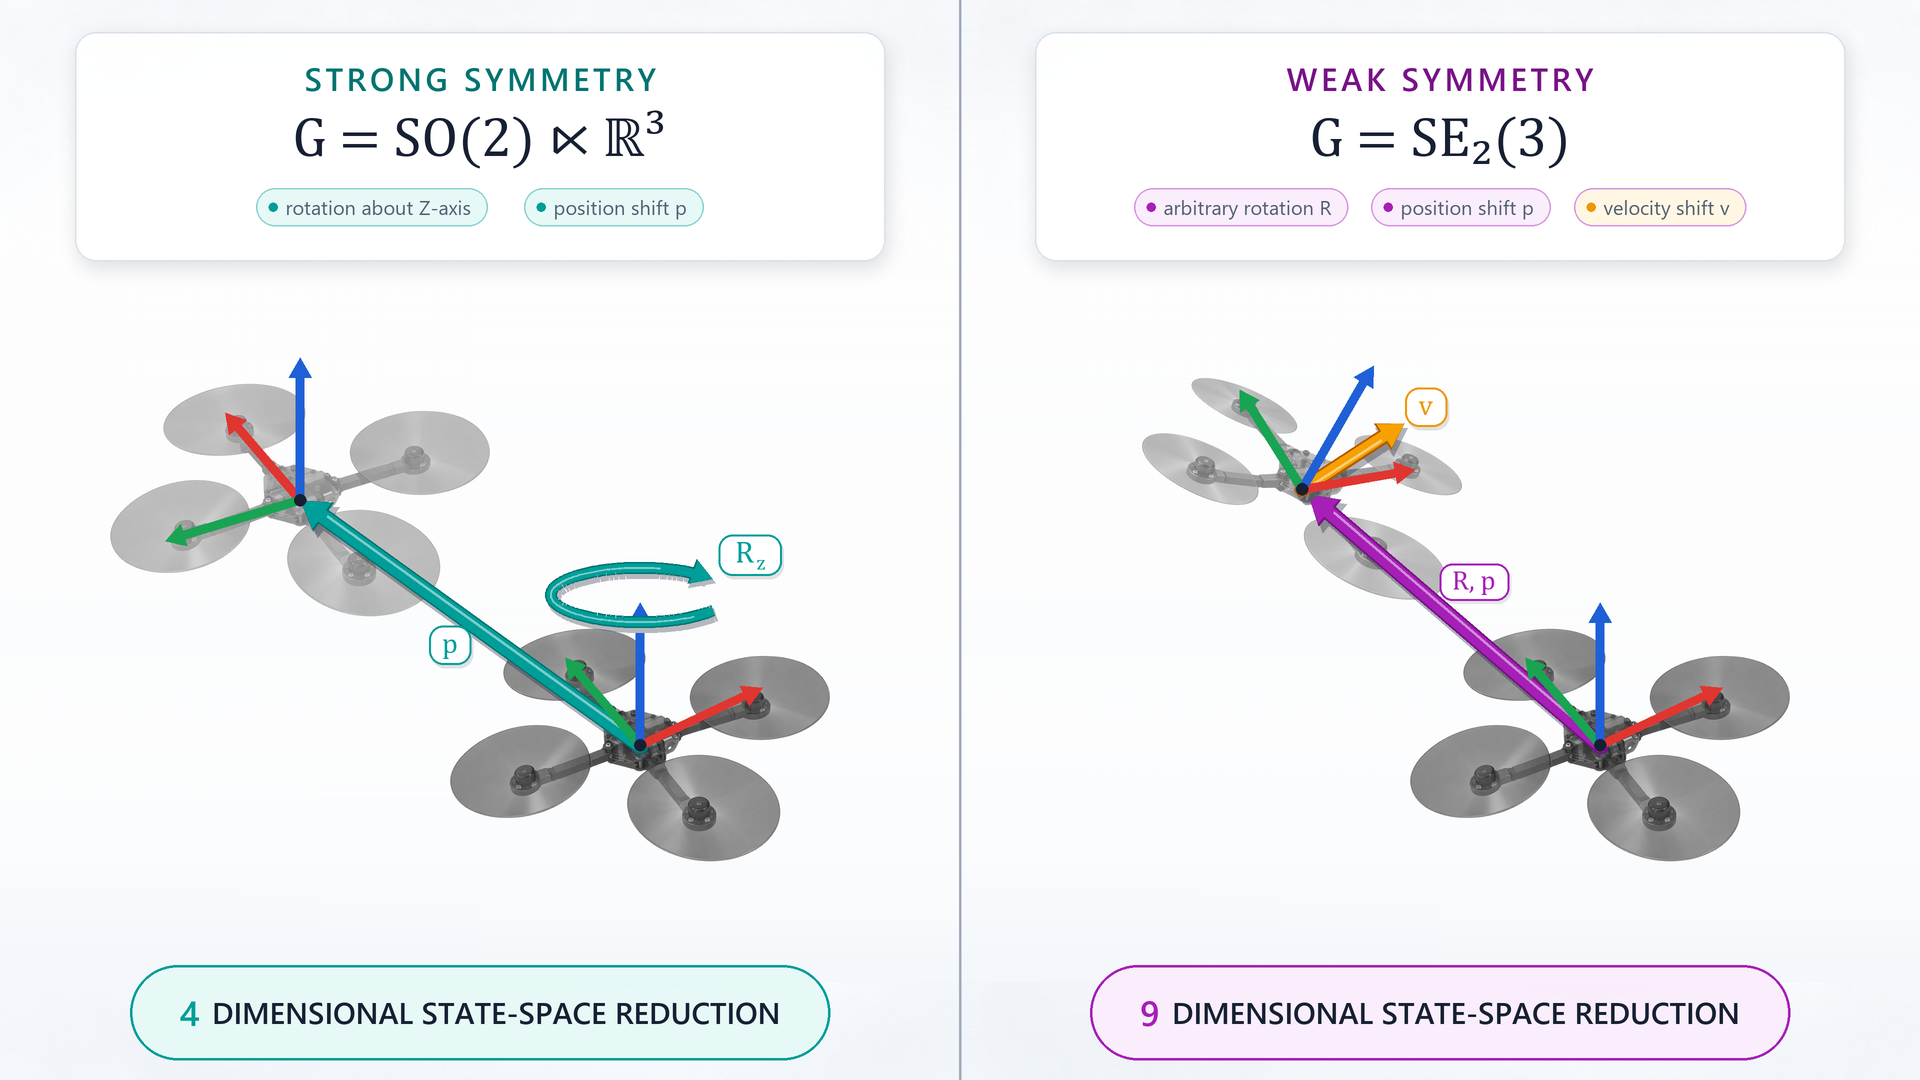
Paper #10 — Reduction of Tracking Control Problems under Weak Symmetry

Authors: Riley Link, Pieter van Goor, Jake Welde

Institutions: Cornell University; University of Sydney

Download Paper (PDF)
Paper #10 Teaser Figure

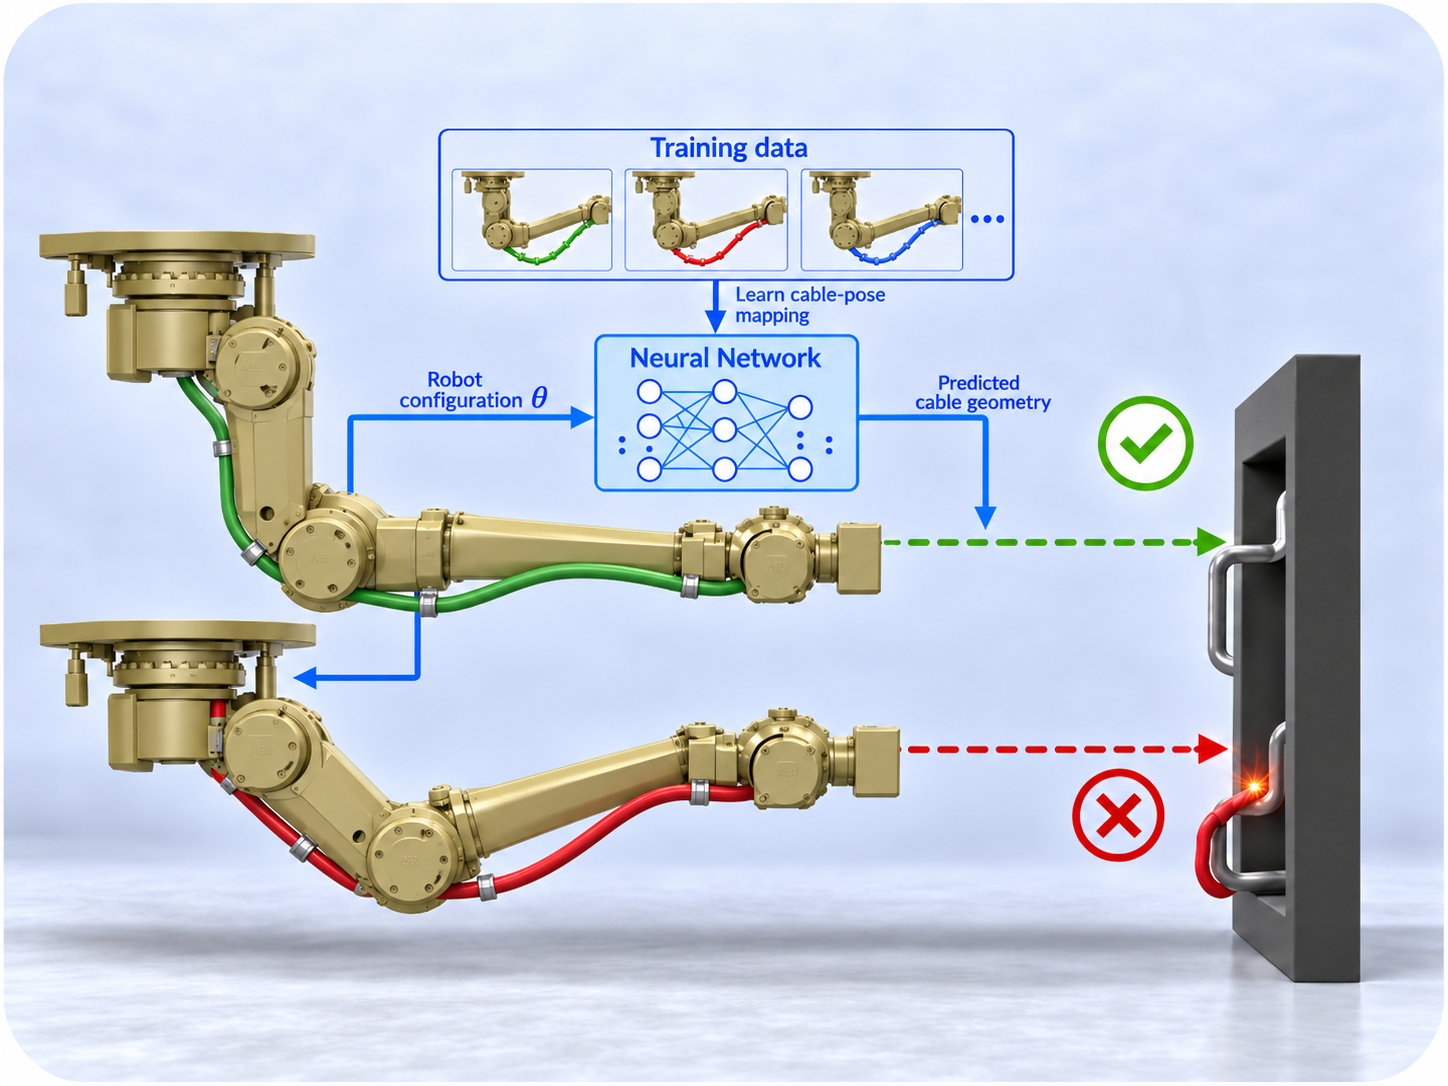
Paper #11 — Learning Deformable Cable Geometry for Collision-Free Planning of Construction Robots

Authors: Karthik Shaji, Edvard Bruun, Frank Dellaert

Institution: Georgia Institute of Technology

Download Paper (PDF)
Paper #11 Teaser Figure

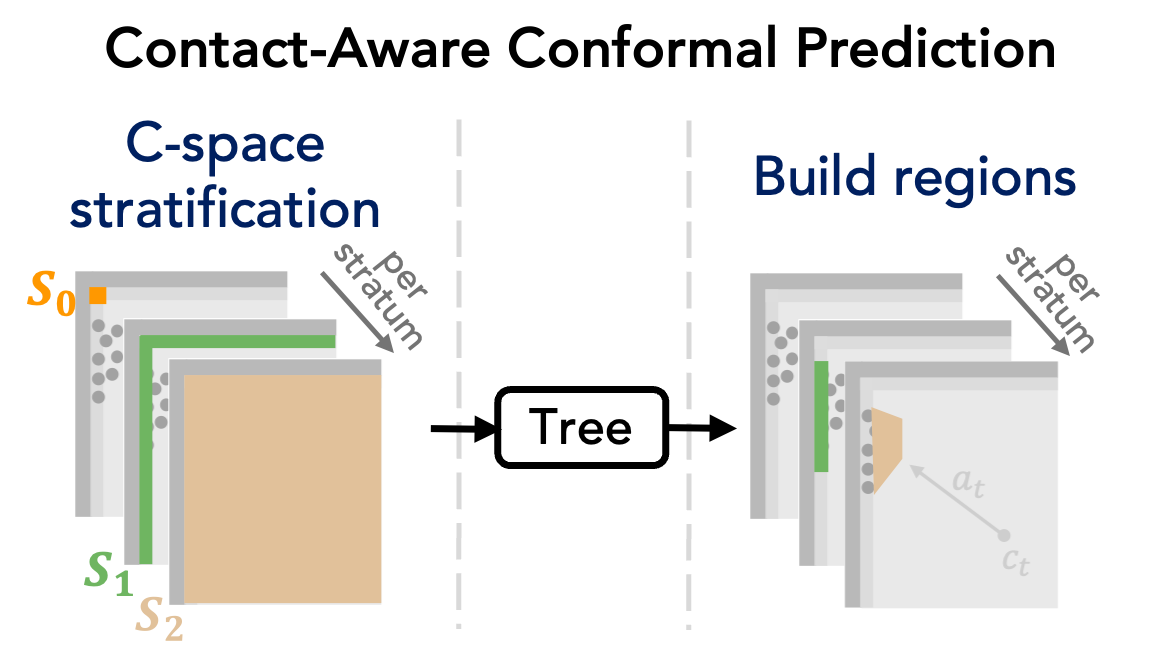
Paper #12 — Calibrating Motion Uncertainty on Contact-Stratified Configuration Spaces

Authors: Luís Marques, Kristian Popov, Dmitry Berenson

Institution: University of Michigan

Download Paper (PDF)
Paper #12 Teaser Figure

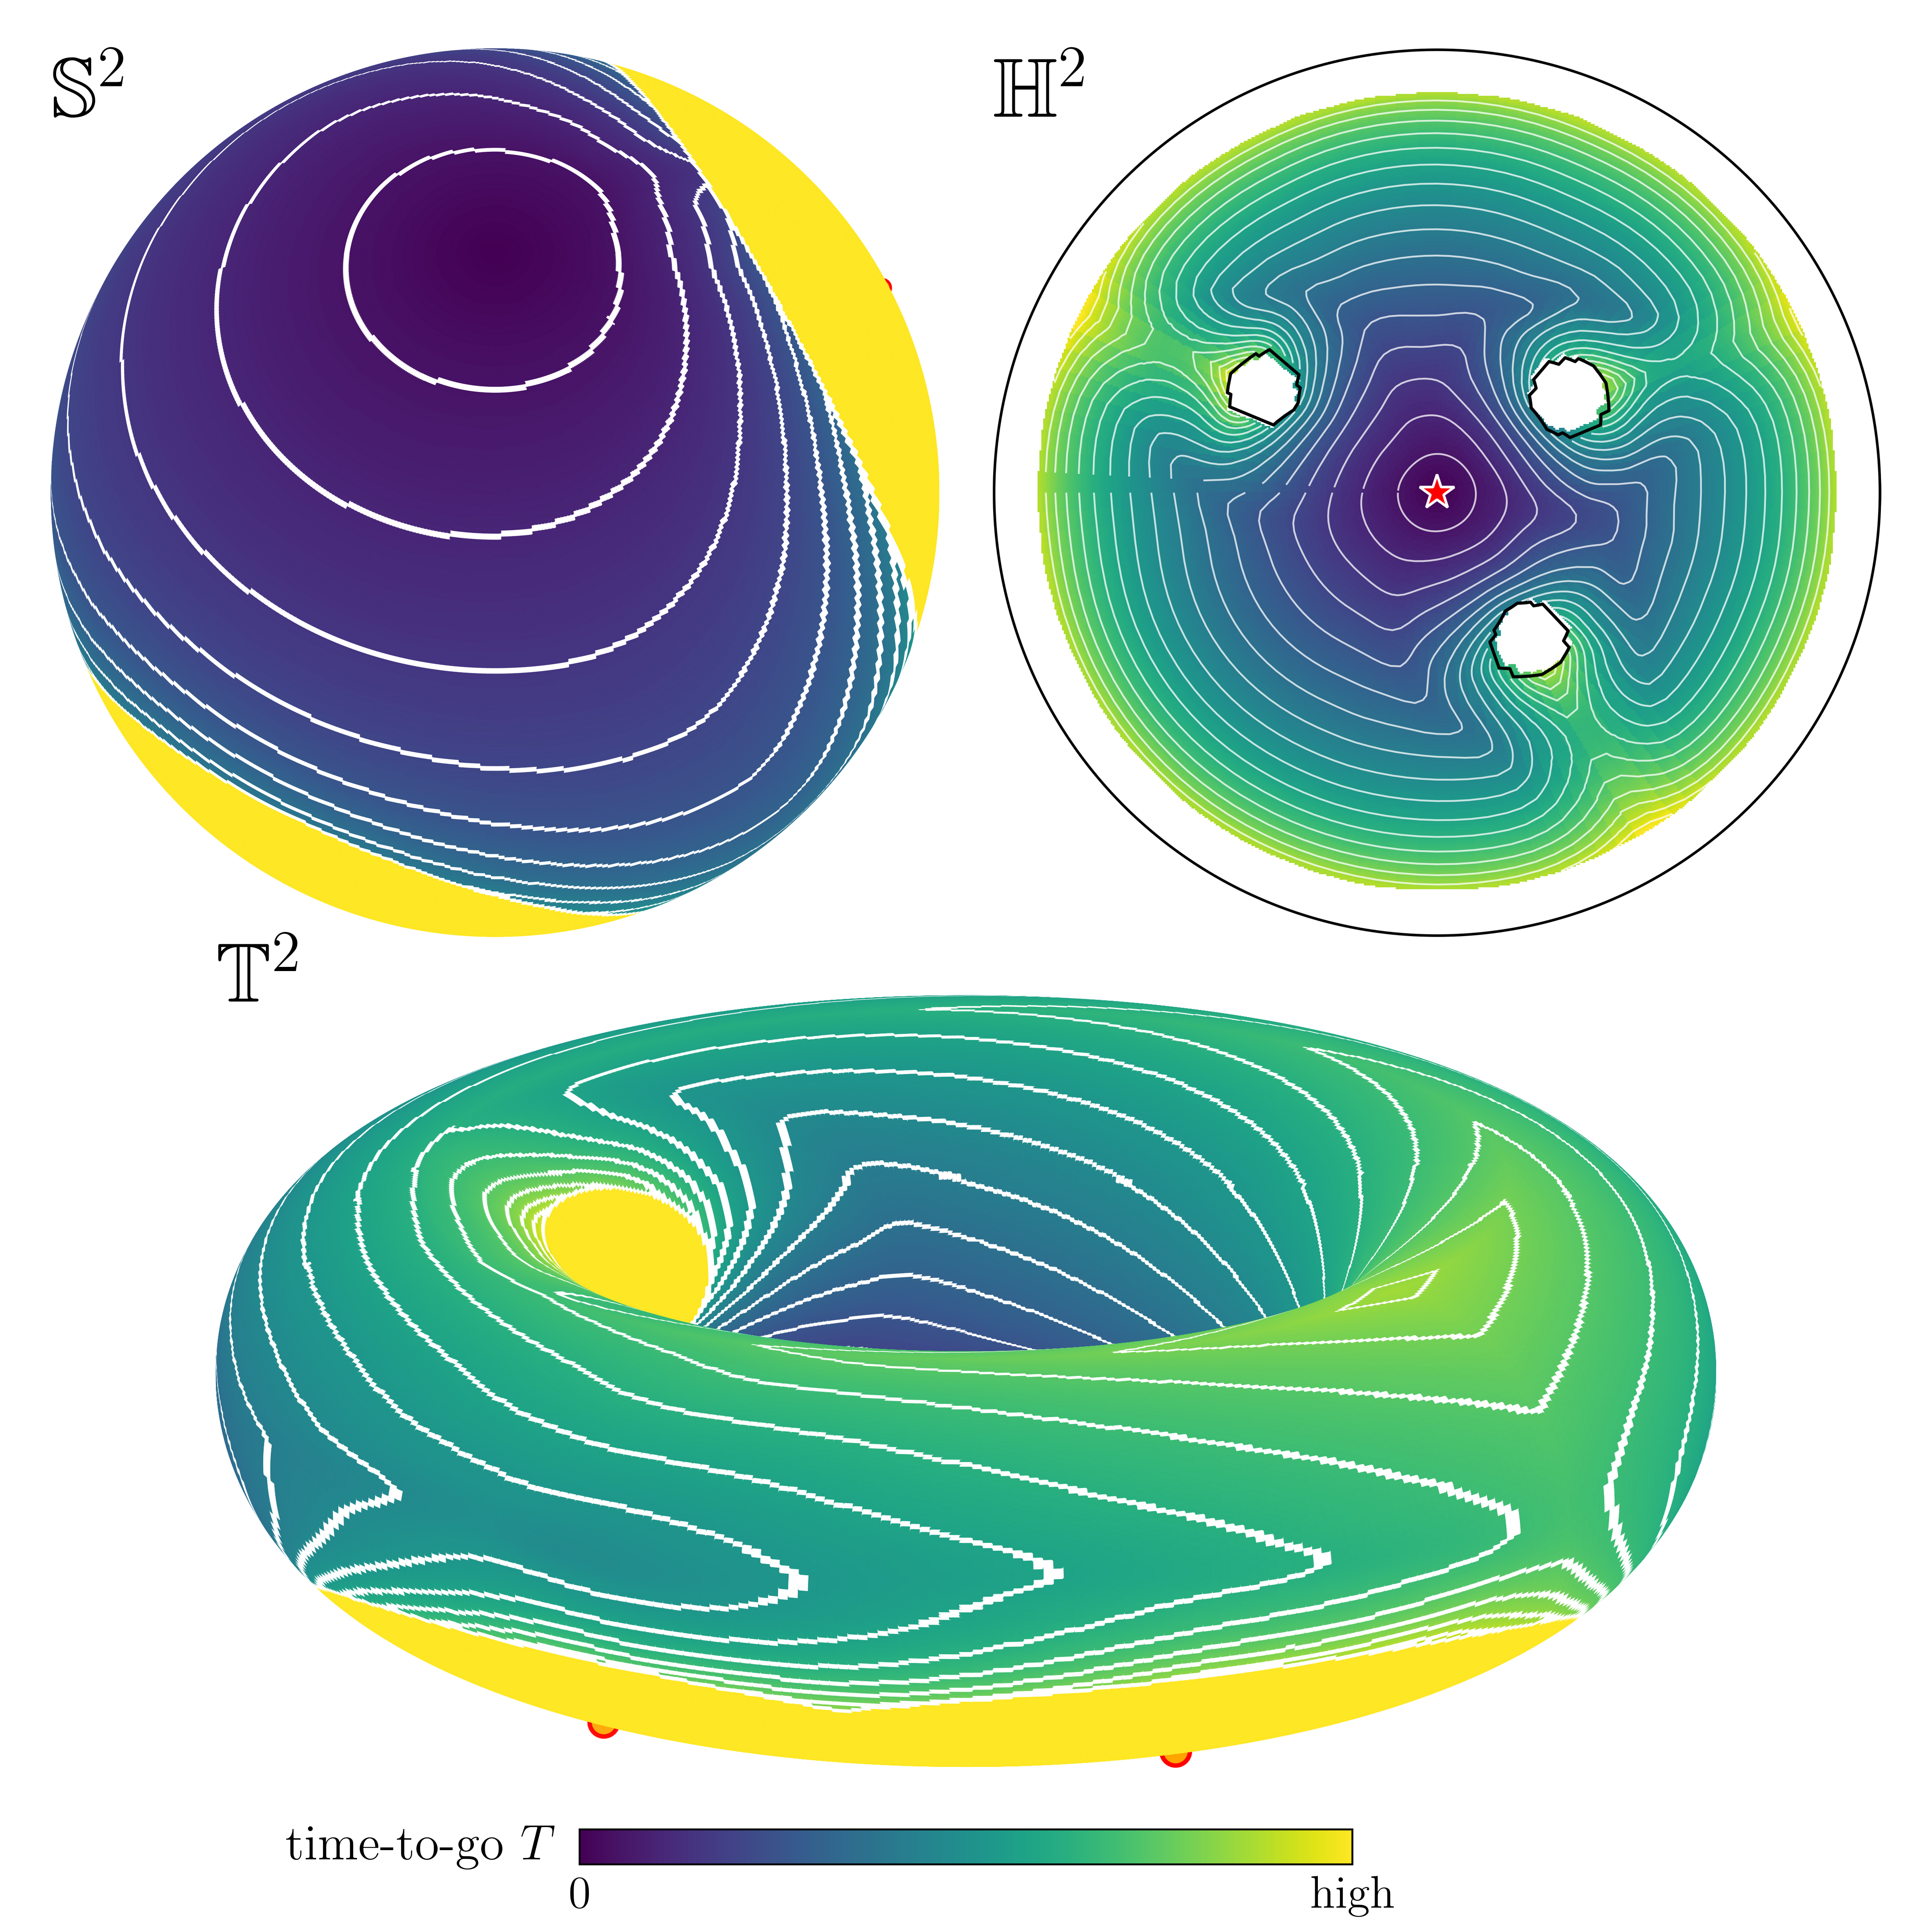
Paper #13 — Riemannian Splat Regression Models for Learning Time Fields on Arbitrary Riemannian Manifolds

Authors: Anastasios Manganaris, Rohit Banerjee, Gokul Prabhakaran, Ahmed H. Qureshi

Institution: Purdue University

Download Paper (PDF)
Paper #13 Teaser Figure

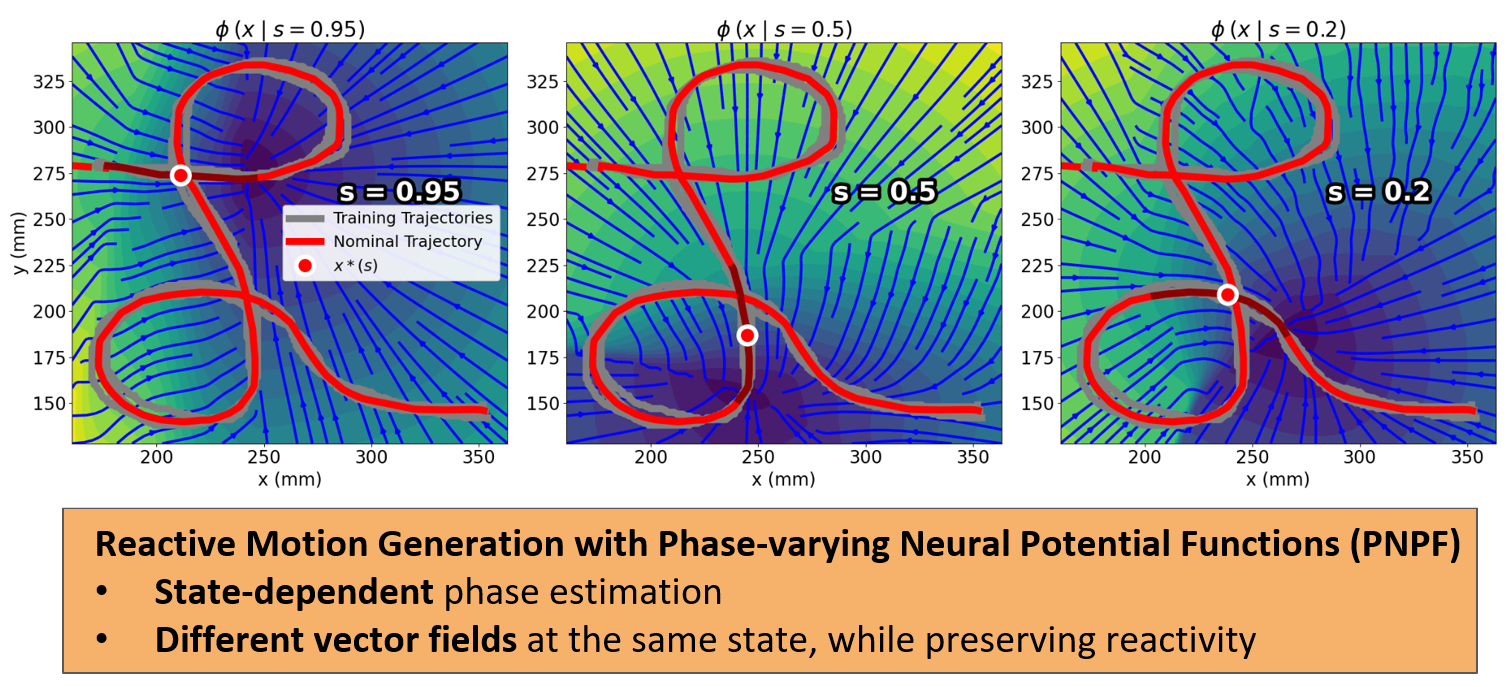
Paper #14 — Phase-Varying Neural Potential Functions for Reactive Robot Motions

Authors: Ahmet Tekden, Dimitrios Kanoulas, Aude Billard, Yasemin Bekiroglu

Institutions: Chalmers University of Technology; University College London; École Polytechnique Fédérale de Lausanne (EPFL)

Download Paper (PDF)
Paper #14 Teaser Figure

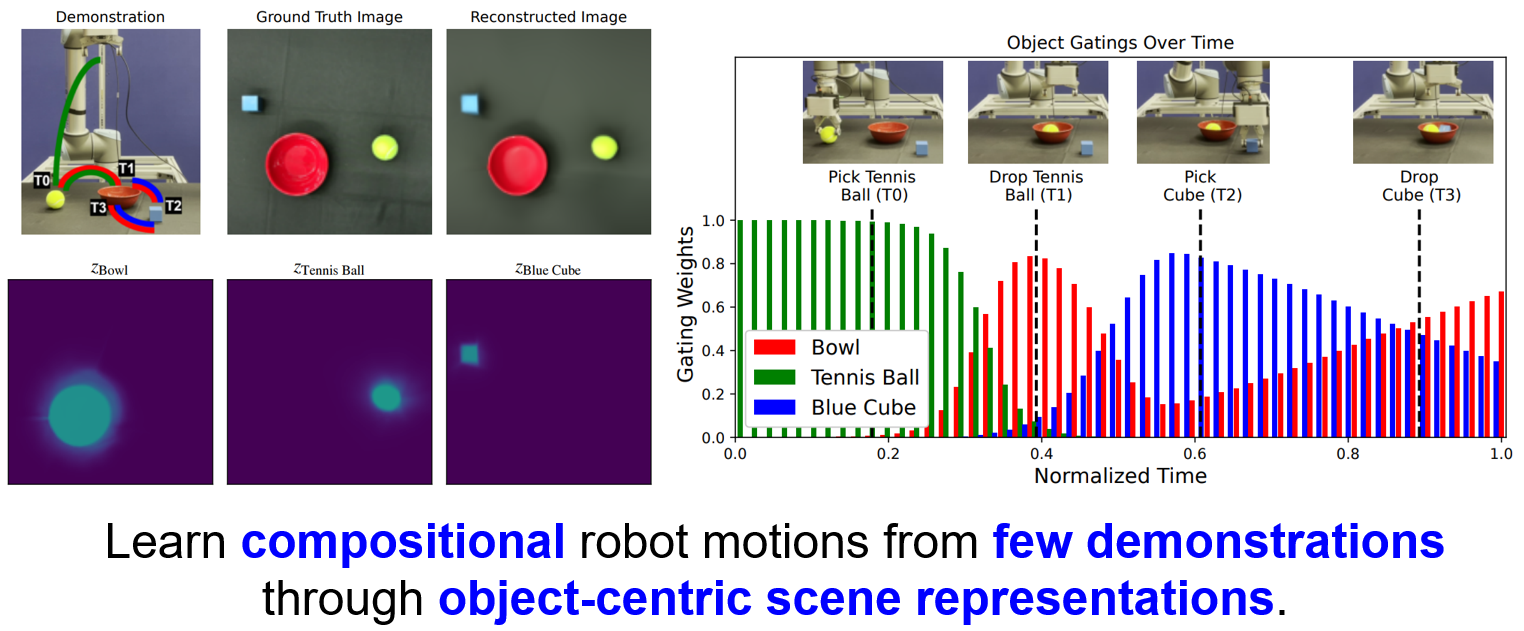
Paper #15 — Compositional Scene-Motion Learning via Object-Centric Neural Representations

Authors: Ahmet Tekden, Yasemin Bekiroglu

Institutions: Chalmers University of Technology; University College London

Download Paper (PDF)
Paper #15 Teaser Figure

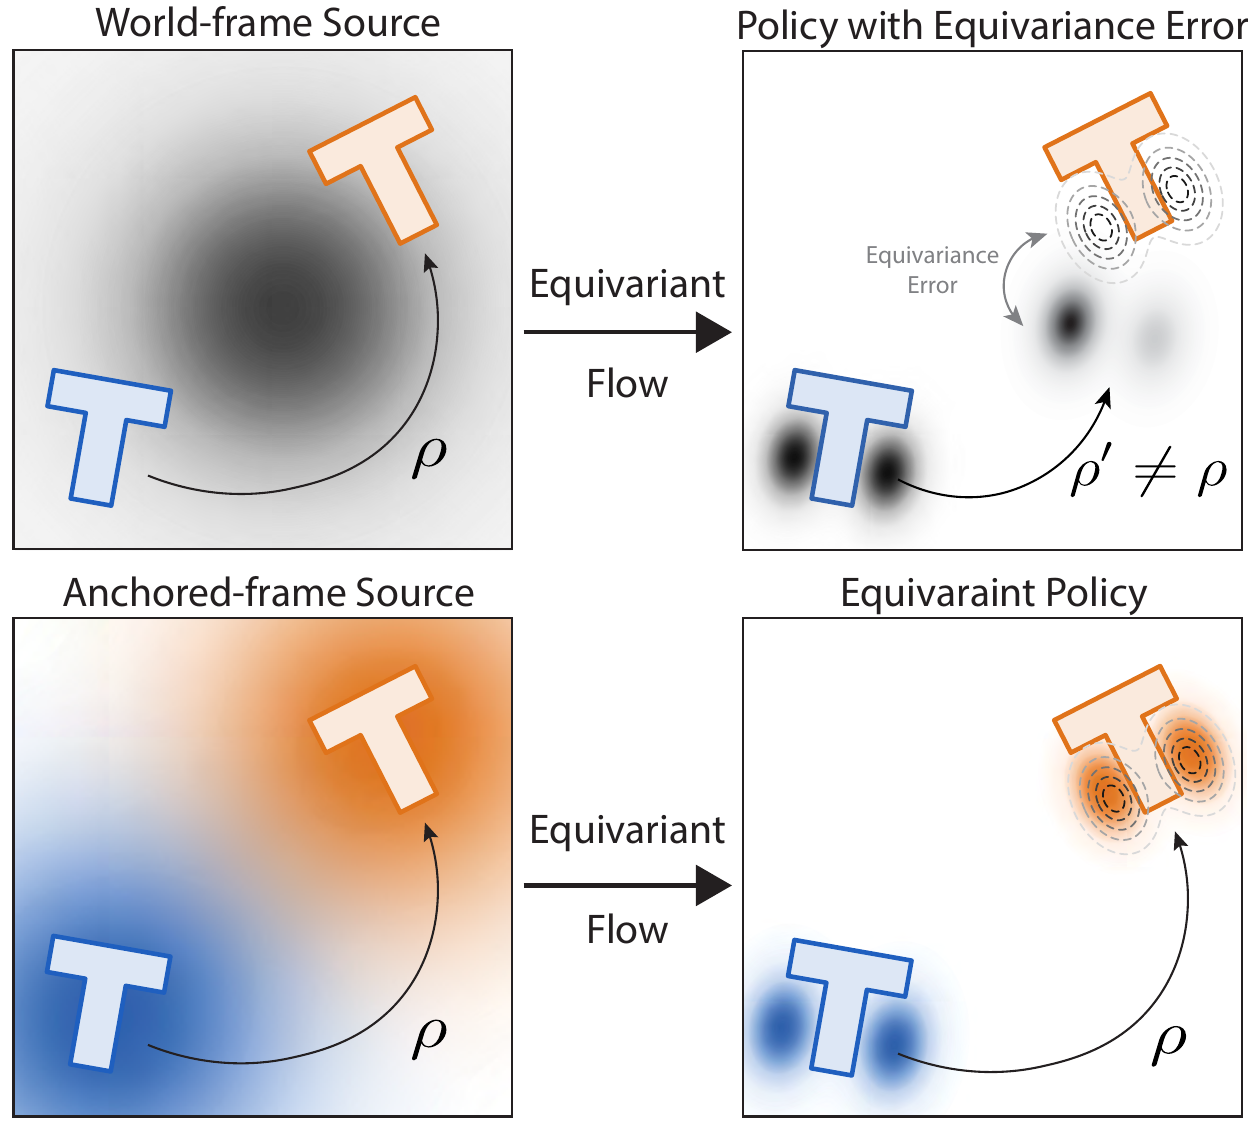
Paper #16 — Equivariance Begins at the Source: Quantifying and Characterizing Source Distributions for Generative Robot Policies

Authors: Keqin Wang, Tao Zhong, Christine Allen-Blanchette

Institution: Princeton University

Download Paper (PDF)
Paper #16 Teaser Figure

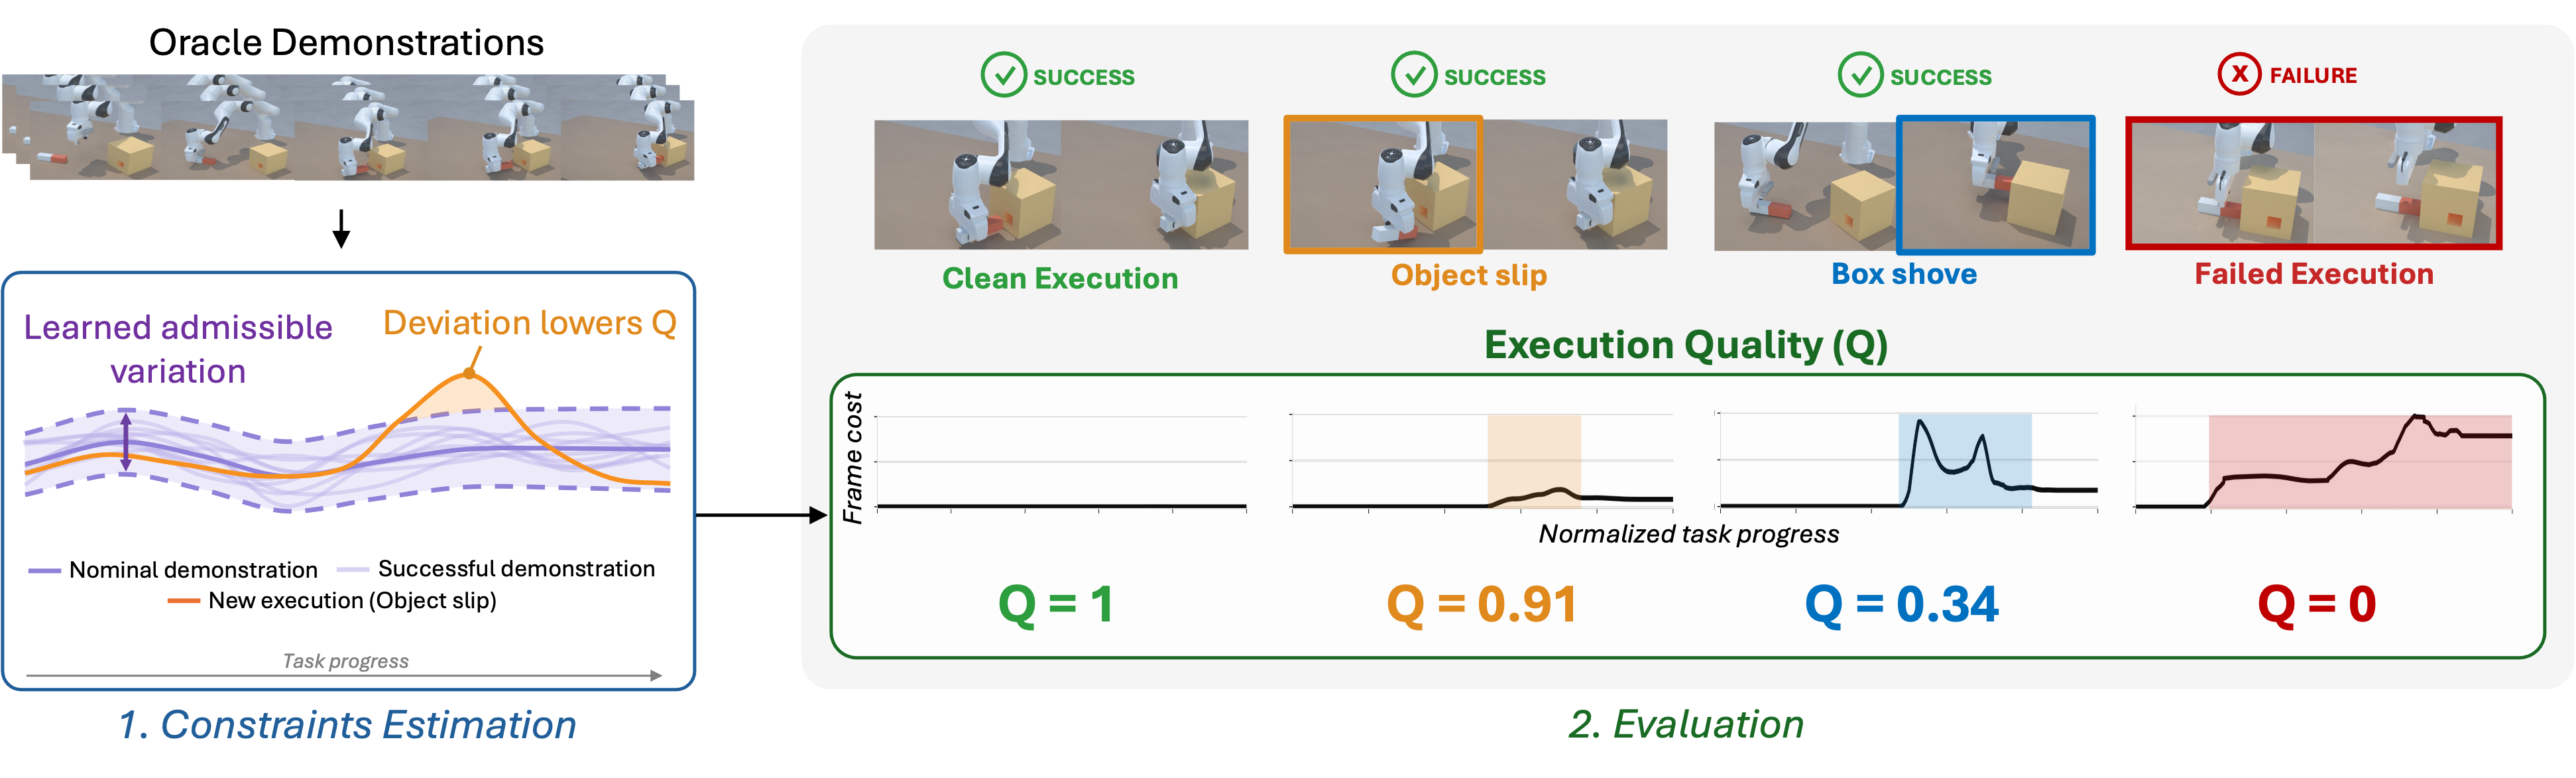
Paper #17 — Shades of Success: Characterizing Manipulation Quality through Object-Centric Constraints

Authors: Lorena Maria Genua, Sarvesh Prajapati, Ananya Trivedi, Taşkın Padır

Institution: Northeastern University

Download Paper (PDF)
Paper #17 Teaser Figure

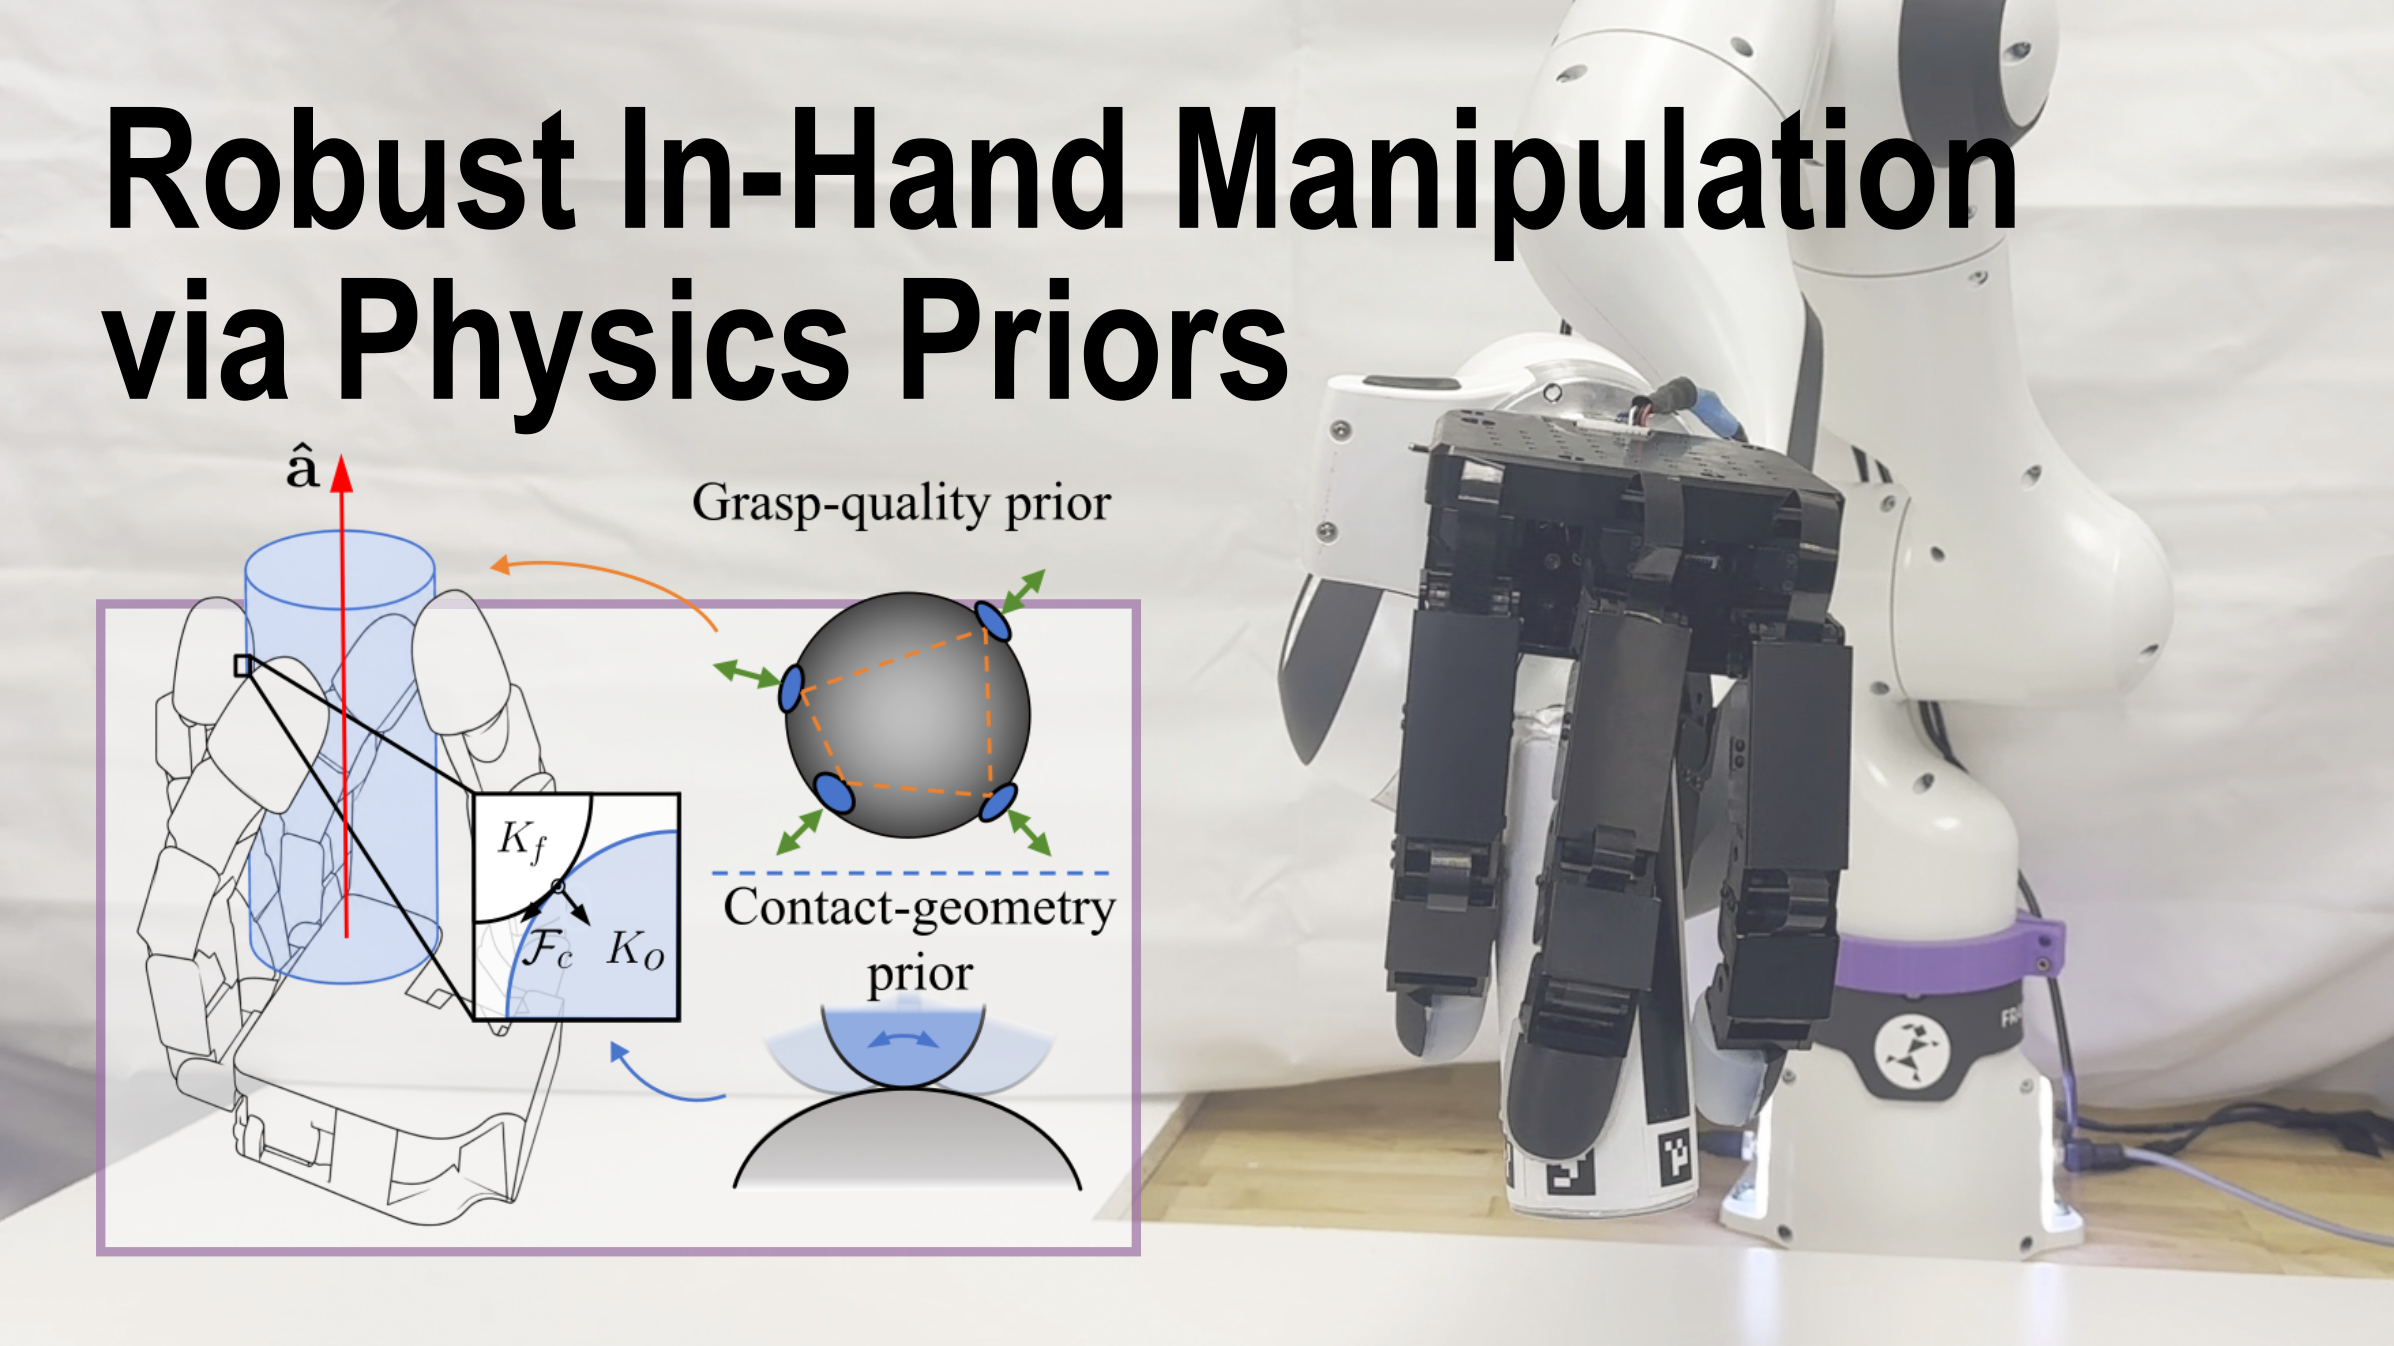
Paper #18 — Robust In-Hand Manipulation via Priors from Grasp Quality and Contact Geometry

Authors: Shihan Lu, Yifei Chen, Ed Colgate, Kevin Lynch

Institution: Northwestern University

Download Paper (PDF)
Paper #18 Teaser Figure

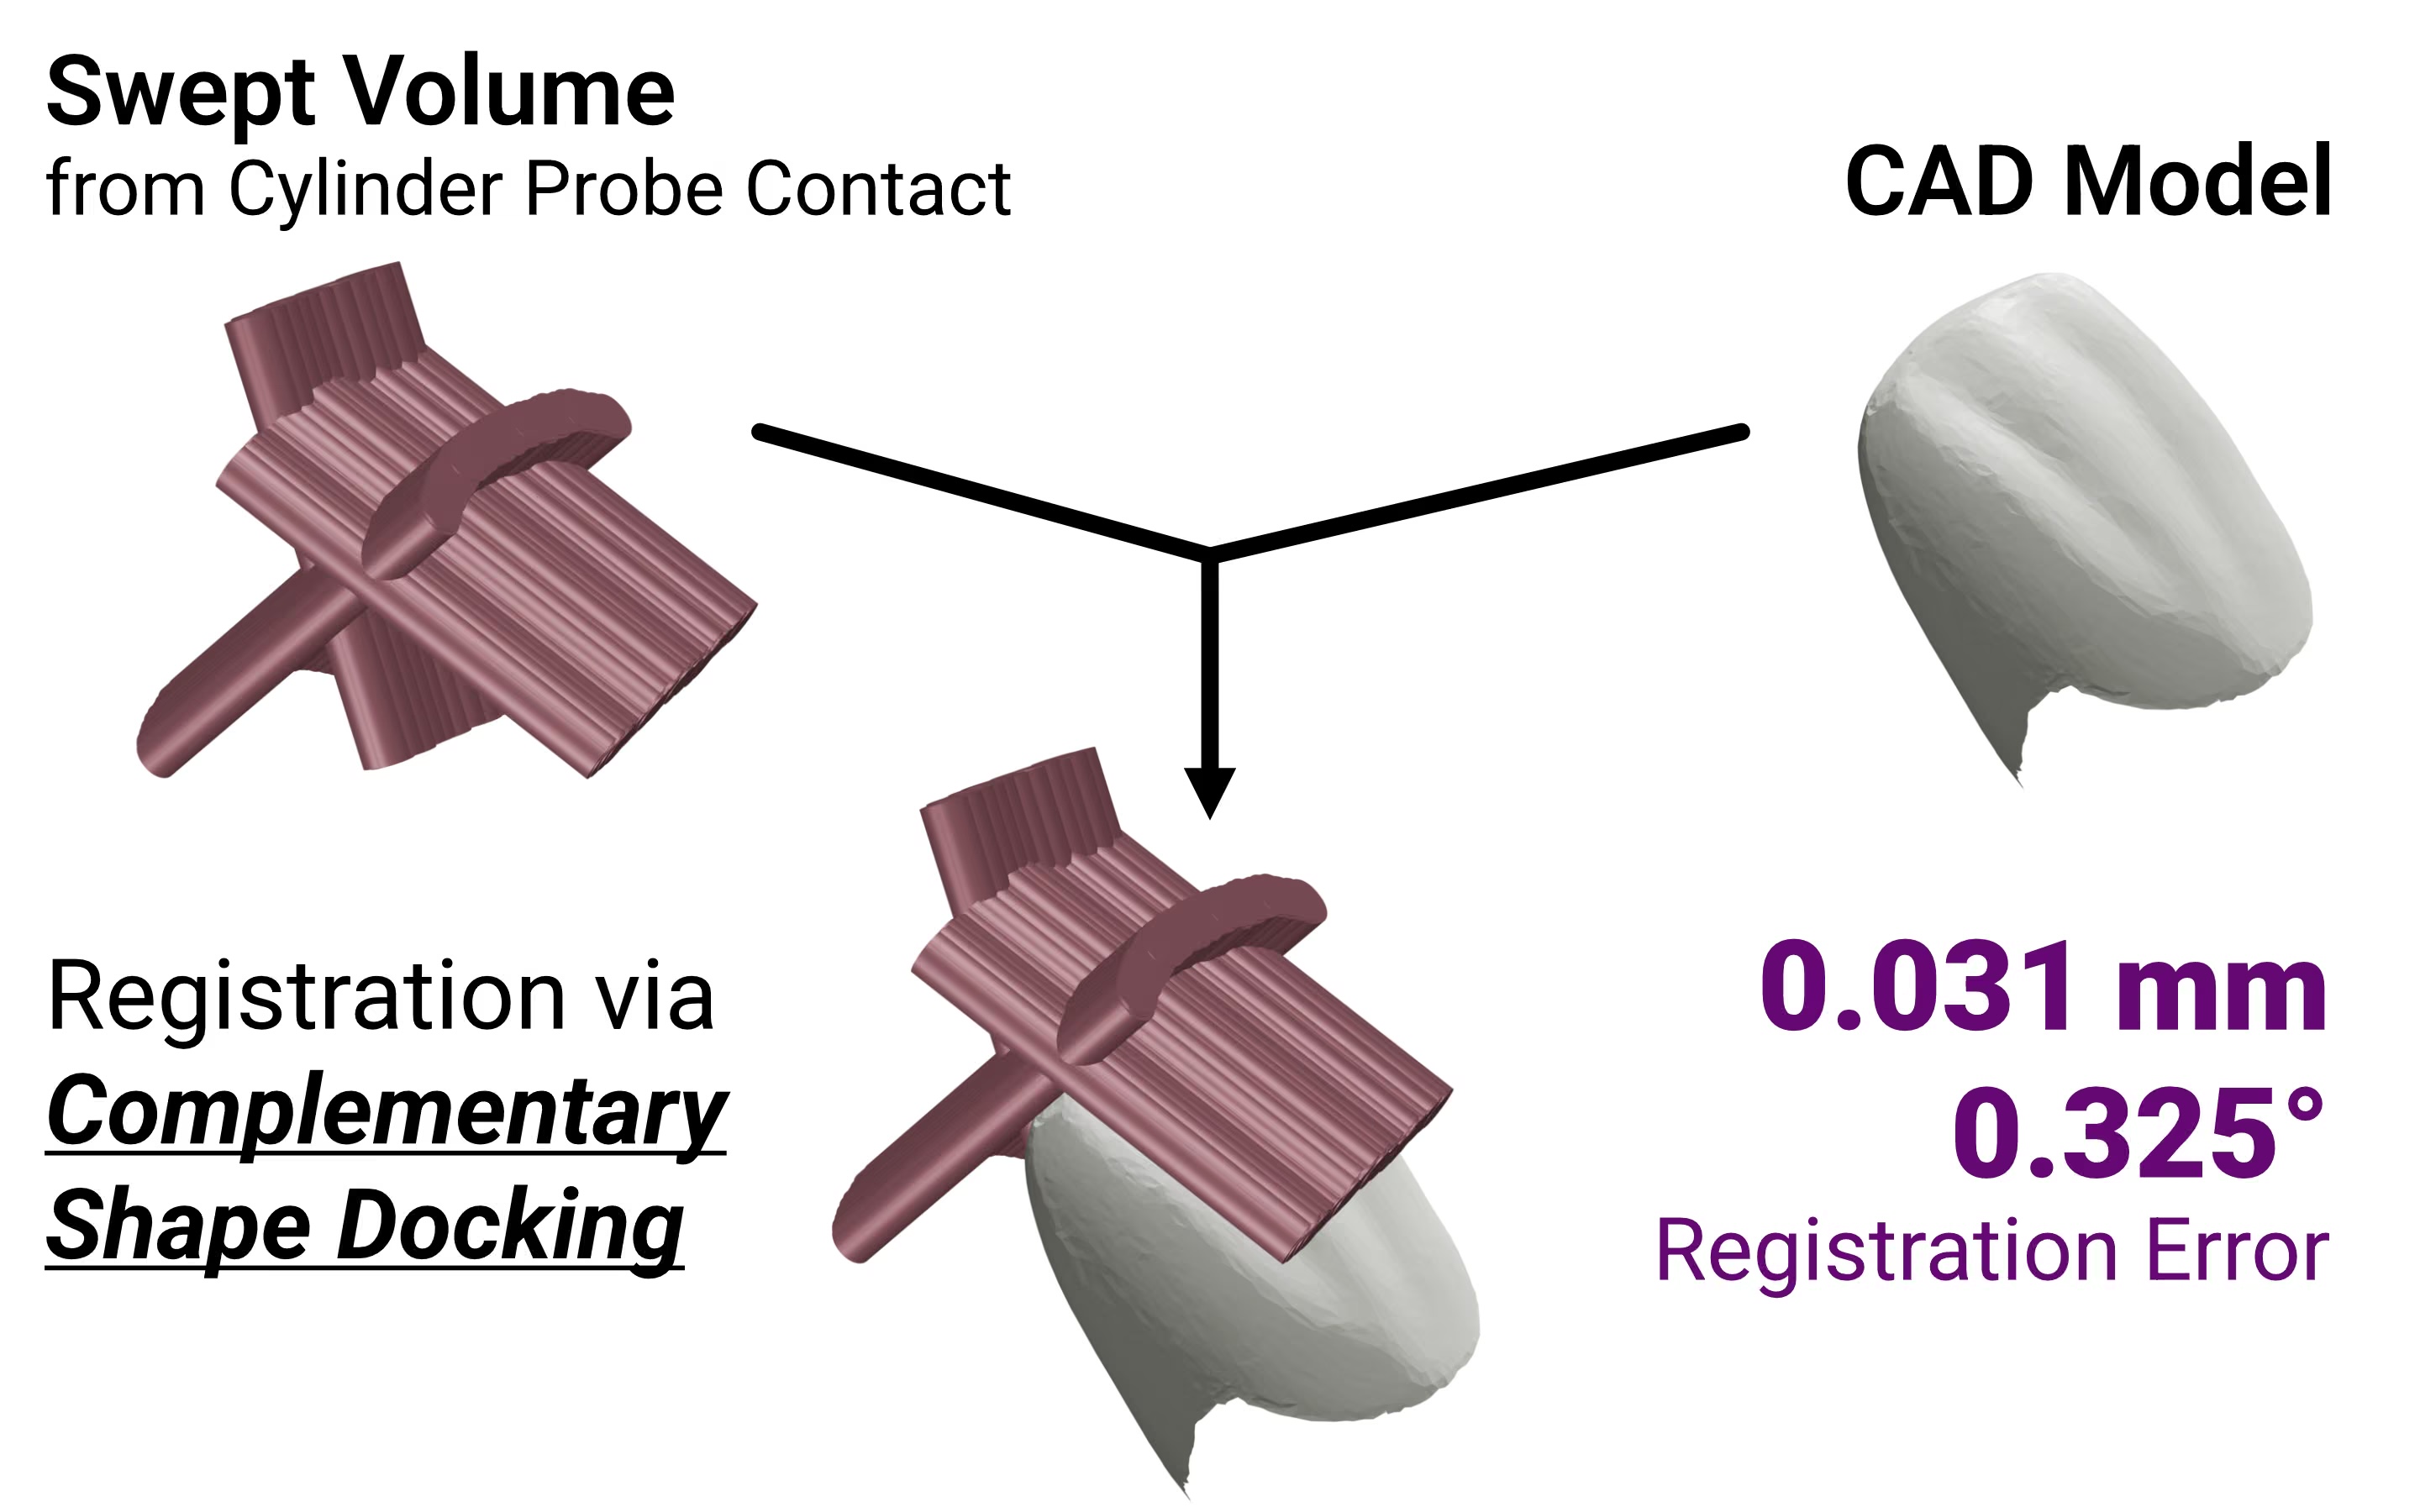
Paper #19 — From Swept Contact to Pose: Probe-Aware Registration via Complementary-Shape Docking

Authors: Chen Chen, Yunwen Li, Yifan Xu, Xiangjie Yan, Chang Shu, Jianxia Hou, Shiji Song, Xiang Li

Institutions: Tsinghua University; Tsingscribe Medical Ltd.; ETH Zurich; Peking University School and Hospital of Stomatology

Download Paper (PDF)
Paper #19 Teaser Figure

Paper #20 — When the Prior Becomes the Measurement: Learning-Augmented Equivariant Filtering for Unaided Inertial Navigation

Authors: Aya Lafdili, Blaise Mulliez, Hélène Tap

Institution: LAAS-CNRS / Toulouse INP-ENSEEIHT, France

Paper #21 — GRIP: Sparse Geometric Interaction Graphs for Contact-Rich Manipulation

Authors: Charuvahan Adhivarahan, Sai Ram Kasanagottu, Dasharadhan Mahalingam, Nilanjan Chakraborty, Karthik Dantu

Institutions: University at Buffalo; Stony Brook University

IEEE/RSJ IROS 2026 Workshop — Geometric Representations in Robotics